Flagship open platform · Build package
Build Dropbear
Hyperspawn Robotics · Humanoid · active · 2023
Full-size open-source humanoid from Hyperspawn and Pointblank: FDM-printed structure on 20x20 aluminium extrusion, MyActuator CAN actuators, an ESP32 node per limb and a Jetson Orin brain. CAD, BOM, printables, firmware, URDF/MJCF/USD and simulation walking policies are public; a pre-assembled kit is on preorder.
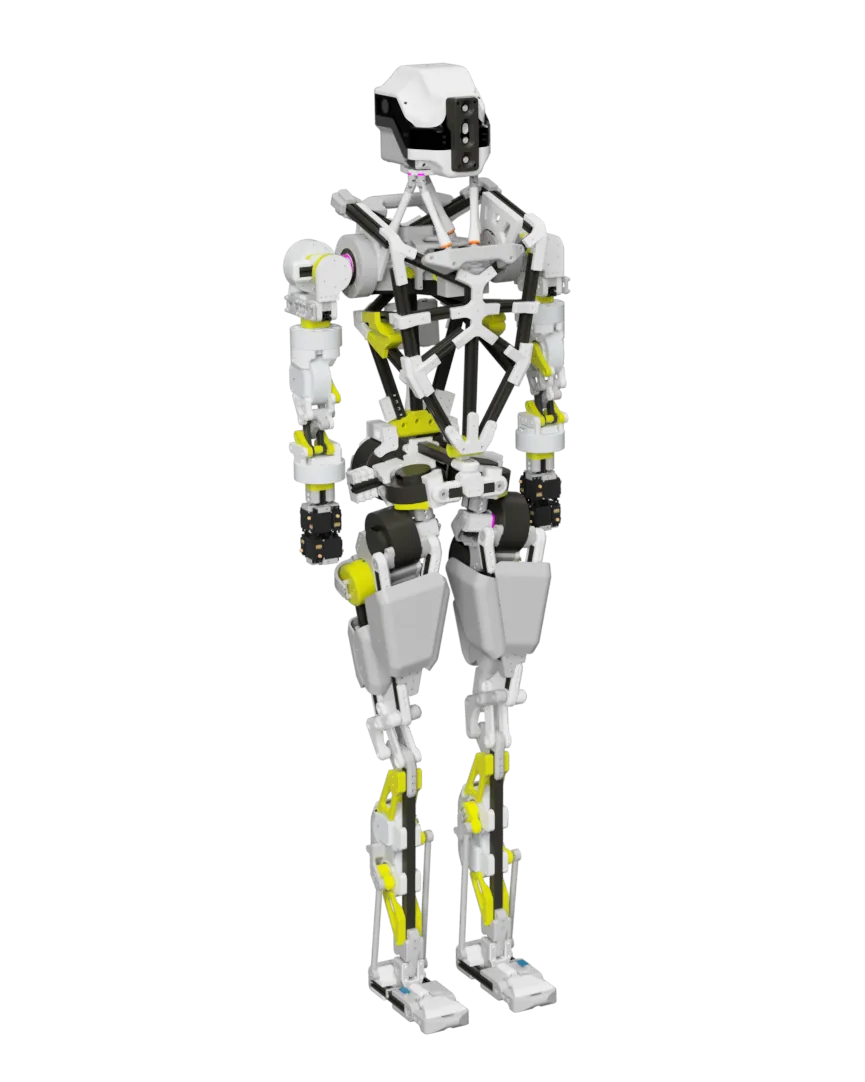
- Drawing
- /hyperspawn/dropbear
- Maker
- Hyperspawn Robotics
- Country
- IN
- Package rev
- v0.2.0
- Level
- L2 Sim-verified
- Availability
- Preorder
- Openness
- 100/100
- HW licence
- MIT AND Hyperspawn-License
- Last checked
- 2026-09-25
- Height
- 180 cm
- Mass
- 45 kg
- DOF
- 32
- Actuators
- MyActuator RMD-X10, RMD-X8, RMD-X6 and CEM-60 over 1 Mbit/s CAN (18 per the 2026 BOM; myactuator-can lists 12 RMD-X8 Pro, 4 RMD-X10 V3, 6 CEM-60); 6 NEMA 17 lead-screw steppers in the Stewart-platform neck. hyperspawn.ai: servo + QDD.
Reference implementation of the ORP spec; gets no ranking advantage anywhere in the suite. Three ways to get one: preorder the assembled kit ($9,999, $500 deposit, Q2 2027), self-source from the open BOM, or print and build from the repos. Level 2 (sim-verified), not 4: no physical walking is published and the locomotion repo calls its policies simulation releases; the v0.1.0 policy passed 128/128 zero-fall 20 s trials at 0.20 m/s in sim, so no top speed is listed. Spec sources conflict and the most recent official statement (hyperspawn.ai, 2026) is used: 1.8 m (home page says 6 ft), 45 kg (URDF sums to 47.7 kg, MJCF to 34.0 kg), 32 DOF (dropbear_firmware configures 31 joints across 6 limb nodes; the locomotion policy drives 14), 48 V battery (home-page label reads 24 V), 2–4 h runtime (lower bound stored). Battery energy is the BOM's 48 V 20 Ah pack. Licenses: most sub-repos are MIT (bom.md's footer says CC BY 4.0); the main Dropbear repo uses the non-commercial Hyperspawn License; dropbear-locomotion (code, weights, USD, media) is CC BY-NC-SA 4.0.
Configure
Saved in the URL. Share the link to share the build.Source
One cart across 7 vendors · prices in USD as listedHyperspawn Robotics sells this robot. Buying from the maker funds the people who opened the design. No BOM line below lists them as a vendor yet, so check their store before ordering parts one by one.
94 lines · 1,539 parts · 12 without an offer in US · 79/94 lines sourced in 2+ regions (L3 gate)
| # | Part | Category | Qty | Unit | Line | Offer |
|---|---|---|---|---|---|---|
NVIDIA Store1 line · $1,999.00 | ||||||
| 1 | NVIDIA Jetson AGX Orin 64GB Developer Kit (275 TOPS) compute.jetson · MPN 945-13730-0050-000 · 2 alt | compute | 1 | $1,999.00list price | $1,999.00 | NVIDIA Store |
RealSense Store1 line · $399.00 | ||||||
| 2 | Intel RealSense D455f depth camera (1280x800, 90 fps, IP52) sensor.depth-camera | sensor | 1 | $399.00list price | $399.00 | RealSense Store |
Amazon18 lines · $348.00 + 3 unpriced | ||||||
| 3 | 4G LTE Wi-Fi router (WE826-Q), head electronics.lte-router | electronics | 1 | $89.00list price | $89.00 | AmazonSearch page cited in the Dropbear BOM |
| 4 | 2.4 GHz FPV antenna, RP-SMA male, 2 dBi (2 with cable, or 4 without; match router ports) electronics.antenna | electronics | 2 | $8.00list price | $16.00 | AmazonSearch page cited in the Dropbear BOM |
| 5 | Easycargo 30 mm fan, 5 V / 3.3 V DC electronics.fan-30mm | electronics | 2 | $7.00list price | $14.00 | AmazonSearch page cited in the Dropbear BOM |
| 6 | A4988 driver shield / breakout board, 24-48 V: neck electronics.stepper-shield | electronics | 6 | $6.00list price | $36.00 | AmazonSearch page cited in the Dropbear BOM |
| 7 | M8 (T8, 2 mm pitch) lead screw, 100 mm: neck legs structure.leadscrew-t8 · 1 alt | structure | 6 | unpriced | — | AmazonSearch page cited in the Dropbear BOM |
| 8 | T8 4-start lead-screw nut, brass, anti-backlash: neck structure.t8-nut | structure | 6 | $3.00list price | $18.00 | AmazonSearch page cited in the Dropbear BOM |
| 9 | Universal joint 5x8 mm, stainless: stepper to lead screw structure.ujoint-5x8 | structure | 6 | $3.50list price | $21.00 | AmazonSearch page cited in the Dropbear BOM |
| 10 | Universal joint 8x8 mm, stainless: neck to head structure.ujoint-8x8 · 1 alt | structure | 6 | $4.00list price | $24.00 | AmazonSearch page cited in the Dropbear BOM |
| 11 | Jumper wires F-F 20 cm, 2.54 mm (pack of 40): neck driver wiring cable.jumpers | cable | 1 | $3.00list price | $3.00 | AmazonSearch page cited in the Dropbear BOM |
| 12 | Half-bridge load cell, 50 kg (4 per foot) sensor.load-cell | sensor | 8 | unpriced | — | AmazonSearch page cited in the Dropbear BOM |
| 13 | HX711 load-cell amplifier, one per load cell (modified for 80 Hz) electronics.hx711 · 1 alt | electronics | 8 | unpriced | — | AmazonSearch page cited in the Dropbear BOM |
| 14 | 48 V Li-ion smart charger (54.6 V, 10 A) power.charger | power | 1 | $55.00list price | $55.00 | AmazonSearch page cited in the Dropbear BOM |
| 15 | 48 V voltage display module, 3-wire power.voltmeter | power | 1 | $5.00list price | $5.00 | AmazonSearch page cited in the Dropbear BOM |
| 16 | XT30 1-to-2 power splitter (torso, arms, pelvis, legs) cable.xt30-splitter | cable | 4 | $2.50list price | $10.00 | AmazonSearch page cited in the Dropbear BOM |
| 17 | XT60 1-to-2 power splitter (pelvis, legs) cable.xt60-splitter | cable | 2 | $3.50list price | $7.00 | AmazonSearch page cited in the Dropbear BOM |
| 18 | Tie rod 8 mm x 210 mm, steel, M8 ends: ankle drive structure.tie-rod-210 | structure | 2 | $6.00list price | $12.00 | AmazonSearch page cited in the Dropbear BOM |
| 19 | Tie rod 8 mm x 290 mm, steel, M8 ends: ankle drive structure.tie-rod-290 | structure | 2 | $7.00list price | $14.00 | AmazonSearch page cited in the Dropbear BOM |
| 20 | Rod end bearing, female M8x1.25 (FK8) structure.rod-end-m8 | structure | 8 | $3.00list price | $24.00 | AmazonSearch page cited in the Dropbear BOM |
DigiKey8 lines · $221.40 | ||||||
| 21 | NEMA 17 stepper, 1.8°, 42x40 mm, 0.4 Nm: Stewart-platform neck actuator.nema17 | actuator | 6 | $15.00list price | $90.00 | DigiKey |
| 22 | ESP32 module, 38-pin (ESP32-DevKitC-V4 / WROOM-32): limb CAN nodes electronics.esp32 · 1 alt | electronics | 5 | $7.00list price | $35.00 | DigiKey |
| 23 | MCP2515 SPI CAN module (CAN 2.0B, 1 Mbps; must carry an 8 MHz crystal) electronics.can-module · MPN MCP2515-I/P · 2 alt | electronics | 4 | $4.50list price | $18.00 | DigiKey |
| 24 | A4988 stepper driver (8-35 V, 2 A): neck electronics.stepper-driver | electronics | 6 | $5.00list price | $30.00 | DigiKey |
| 25 | Emergency stop button, 22 mm, NC, panel mount power.estop | power | 1 | $8.00list price | $8.00 | DigiKey |
| 26 | Inline fuse holder + 40 A blade fuse power.fuse · 1 alt | power | 2 | $5.00list price | $10.00 | DigiKey |
| 27 | XT30 female connector, 30 A (torso 2, arms 4, pelvis 1, legs 1) cable.xt30-female | cable | 8 | $0.80list price | $6.40 | DigiKey |
| 28 | Ball bearing 608ZZ, 8x22x7 mm (pelvis 12, legs 36) structure.bearing-608zz | structure | 48 | $0.50list price | $24.00 | DigiKey |
Misumi9 lines · $138.35 | ||||||
| 29 | 20x20 slot-6 aluminium extrusion, 85 mm (pelvic 1) structure.extrusion-2020-85 | structure | 1 | $1.10list price | $1.10 | MisumiOrder pre-cut to length (BOM tip) |
| 30 | 20x20 slot-6 aluminium extrusion, 100 mm (torso 6, arms 4, legs 2) structure.extrusion-2020-100 | structure | 12 | $1.20list price | $14.40 | MisumiOrder pre-cut to length (BOM tip) |
| 31 | 20x20 slot-6 aluminium extrusion, 150 mm (torso 8, arms 2, pelvic 2, legs 4) structure.extrusion-2020-150 | structure | 16 | $1.80list price | $28.80 | MisumiOrder pre-cut to length (BOM tip) |
| 32 | 20x20 slot-6 aluminium extrusion, 200 mm (torso 10, pelvic 1) structure.extrusion-2020-200 | structure | 11 | $2.40list price | $26.40 | MisumiOrder pre-cut to length (BOM tip) |
| 33 | 20x20 slot-6 aluminium extrusion, 250 mm (legs 2) structure.extrusion-2020-250 | structure | 2 | $3.00list price | $6.00 | MisumiOrder pre-cut to length (BOM tip) |
| 34 | 20x20 slot-6 aluminium extrusion, 300 mm (torso 1, legs 2) structure.extrusion-2020-300 | structure | 3 | $3.60list price | $10.80 | MisumiOrder pre-cut to length (BOM tip) |
| 35 | 20x20 slot-6 aluminium extrusion, 350 mm (torso 1) structure.extrusion-2020-350 | structure | 1 | $4.20list price | $4.20 | MisumiOrder pre-cut to length (BOM tip) |
| 36 | 20x20 slot-6 aluminium extrusion, 400 mm (legs 2) structure.extrusion-2020-400 | structure | 2 | $4.80list price | $9.60 | MisumiOrder pre-cut to length (BOM tip) |
| 37 | Extrusion T-nut M4, slot 6 (torso 155, arms 64, pelvic 28) fastener.tnut-m4-slot6 | fastener | 247 | $0.15list price | $37.05 | Misumi |
McMaster-Carr43 lines · $66.75 | ||||||
| 38 | Countersunk hex socket screw M3 x 10 mm (head 24) fastener.csk-m3x10 | fastener | 24 | $0.04list price | $0.96 | McMaster-Carr |
| 39 | Socket head cap screw M3 x 10 mm (head 24) fastener.shcs-m3x10 | fastener | 24 | $0.04list price | $0.96 | McMaster-Carr |
| 40 | Countersunk hex socket screw M4 x 10 mm (legs 16) fastener.csk-m4x10 | fastener | 16 | $0.05list price | $0.80 | McMaster-Carr |
| 41 | Socket head cap screw M4 x 10 mm (torso 1, arms 42, pelvic 12, legs 64) fastener.shcs-m4x10 | fastener | 119 | $0.05list price | $5.95 | McMaster-Carr |
| 42 | Socket head cap screw M4 x 12 mm (arms 18, head 4, pelvic 28, legs 8) fastener.shcs-m4x12 | fastener | 58 | $0.05list price | $2.90 | McMaster-Carr |
| 43 | Countersunk hex socket screw M4 x 16 mm (torso 86, legs 16) fastener.csk-m4x16 | fastener | 102 | $0.05list price | $5.10 | McMaster-Carr |
| 44 | Socket head cap screw M4 x 16 mm (torso 45, arms 30, head 2, pelvic 26, legs 54) fastener.shcs-m4x16 | fastener | 157 | $0.05list price | $7.85 | McMaster-Carr |
| 45 | Socket head cap screw M4 x 20 mm (torso 18, arms 44, head 9, pelvic 12, legs 56) fastener.shcs-m4x20 | fastener | 139 | $0.05list price | $6.95 | McMaster-Carr |
| 46 | Socket head cap screw M4 x 25 mm (torso 4, arms 10, head 6, legs 2) fastener.shcs-m4x25 | fastener | 22 | $0.06list price | $1.32 | McMaster-Carr |
| 47 | Socket head cap screw M4 x 30 mm (arms 4, head 15, legs 2) fastener.shcs-m4x30 | fastener | 21 | $0.06list price | $1.26 | McMaster-Carr |
| 48 | Socket head cap screw M4 x 35 mm (arms 14, pelvic 2, legs 30) fastener.shcs-m4x35 | fastener | 46 | $0.07list price | $3.22 | McMaster-Carr |
| 49 | Socket head cap screw M4 x 40 mm (arms 8, head 2) fastener.shcs-m4x40 | fastener | 10 | $0.07list price | $0.70 | McMaster-Carr |
| 50 | Socket head cap screw M4 x 45 mm (torso 4, head 6, pelvic 2, legs 2) fastener.shcs-m4x45 | fastener | 14 | $0.08list price | $1.12 | McMaster-Carr |
| 51 | Socket head cap screw M4 x 50 mm (head 2, legs 2) fastener.shcs-m4x50 | fastener | 4 | $0.08list price | $0.32 | McMaster-Carr |
| 52 | Socket head cap screw M4 x 55 mm (pelvic 8) fastener.shcs-m4x55 | fastener | 8 | $0.10list price | $0.80 | McMaster-Carr |
| 53 | Socket head cap screw M4 x 60 mm (pelvic 4, legs 4) fastener.shcs-m4x60 | fastener | 8 | $0.11list price | $0.88 | McMaster-Carr |
| 54 | Socket head cap screw M4 x 70 mm (pelvic 12) fastener.shcs-m4x70 | fastener | 12 | $0.12list price | $1.44 | McMaster-Carr |
| 55 | Socket head cap screw M4 x 80 mm (torso 2, legs 10) fastener.shcs-m4x80 | fastener | 12 | $0.13list price | $1.54 | McMaster-Carr |
| 56 | Socket head cap screw M4 x 85 mm (pelvic 4, legs 4) fastener.shcs-m4x85 | fastener | 8 | $0.14list price | $1.12 | McMaster-Carr |
| 57 | Socket head cap screw M4 x 90 mm (pelvic 3) fastener.shcs-m4x90 | fastener | 3 | $0.14list price | $0.42 | McMaster-Carr |
| 58 | Socket head cap screw M5 x 35 mm (arms 8) fastener.shcs-m5x35 | fastener | 8 | $0.08list price | $0.64 | McMaster-Carr |
| 59 | Socket head cap screw M5 x 40 mm (arms 8) fastener.shcs-m5x40 | fastener | 8 | $0.08list price | $0.64 | McMaster-Carr |
| 60 | Socket head cap screw M5 x 45 mm (arms 8, legs 8) fastener.shcs-m5x45 | fastener | 16 | $0.08list price | $1.28 | McMaster-Carr |
| 61 | Socket head cap screw M5 x 50 mm (legs 8) fastener.shcs-m5x50 | fastener | 8 | $0.09list price | $0.72 | McMaster-Carr |
| 62 | Socket head cap screw M5 x 55 mm (arms 8) fastener.shcs-m5x55 | fastener | 8 | $0.10list price | $0.80 | McMaster-Carr |
| 63 | Socket head cap screw M6 x 20 mm (arms 2) fastener.shcs-m6x20 | fastener | 2 | $0.08list price | $0.16 | McMaster-Carr |
| 64 | Socket head cap screw M6 x 25 mm (arms 2) fastener.shcs-m6x25 | fastener | 2 | $0.08list price | $0.16 | McMaster-Carr |
| 65 | Socket head cap screw M6 x 50 mm (arms 8) fastener.shcs-m6x50 | fastener | 8 | $0.10list price | $0.80 | McMaster-Carr |
| 66 | Socket head cap screw M6 x 65 mm (head 6) fastener.shcs-m6x65 | fastener | 6 | $0.12list price | $0.72 | McMaster-Carr |
| 67 | Socket head cap screw M8 x 30 mm (legs 4) fastener.shcs-m8x30 | fastener | 4 | $0.14list price | $0.56 | McMaster-Carr |
| 68 | Socket head cap screw M8 x 35 mm (legs 4) fastener.shcs-m8x35 | fastener | 4 | $0.15list price | $0.60 | McMaster-Carr |
| 69 | Socket head cap screw M8 x 40 mm (pelvic 3) fastener.shcs-m8x40 | fastener | 3 | $0.15list price | $0.45 | McMaster-Carr |
| 70 | Socket head cap screw M8 x 45 mm (legs 6) fastener.shcs-m8x45 | fastener | 6 | $0.16list price | $0.96 | McMaster-Carr |
| 71 | Socket head cap screw M8 x 55 mm (pelvic 2, legs 4) fastener.shcs-m8x55 | fastener | 6 | $0.18list price | $1.08 | McMaster-Carr |
| 72 | Socket head cap screw M8 x 60 mm (legs 6) fastener.shcs-m8x60 | fastener | 6 | $0.19list price | $1.14 | McMaster-Carr |
| 73 | Socket head cap screw M8 x 90 mm (legs 2) fastener.shcs-m8x90 | fastener | 2 | $0.22list price | $0.44 | McMaster-Carr |
| 74 | Socket head cap screw M8 x 120 mm (legs 2) fastener.shcs-m8x120 | fastener | 2 | $0.28list price | $0.56 | McMaster-Carr |
| 75 | Socket head cap screw M8 x 170 mm (pelvic 1) fastener.shcs-m8x170 | fastener | 1 | $0.40list price | $0.40 | McMaster-Carr |
| 76 | Plain hex nut M4 (torso 5) fastener.hexnut-m4 | fastener | 5 | $0.05list price | $0.25 | McMaster-Carr |
| 77 | Hex lock nut (nylon insert) M4 (arms 36, head 47, pelvic 15) fastener.locknut-m4 | fastener | 98 | $0.06list price | $5.88 | McMaster-Carr |
| 78 | Plain hex nut M5 (arms 24) fastener.hexnut-m5 | fastener | 24 | $0.06list price | $1.44 | McMaster-Carr |
| 79 | Hex lock nut (nylon insert) M6 (arms 12) fastener.locknut-m6 | fastener | 12 | $0.08list price | $0.96 | McMaster-Carr |
| 80 | Hex lock nut (nylon insert) M8 (pelvic 5) fastener.locknut-m8 | fastener | 5 | $0.10list price | $0.50 | McMaster-Carr |
Mouser2 lines · $18.00 | ||||||
| 81 | Silicone wire 14 AWG, metres (torso 1, arms 1) cable.wire-14awg | cable | 2 | $3.00list price | $6.00 | Mouserships globally |
| 82 | Silicone wire 12 AWG, metres (pelvis 1, legs 2) cable.wire-12awg | cable | 3 | $4.00list price | $12.00 | Mouserships globally |
No offer in this region12 lines · $6,757.40 + 5 unpriced | ||||||
| 83 | MyActuator RMD-X10 (24-48 V, CAN, 50 Nm): 2 torso waist + 2 pelvis actuator.rmd-x10 · 1 alt | actuator | 4 | $650.00list price | $2,600.00 | Offers in CN only |
| 84 | MyActuator RMD-X8 (24-48 V, CAN, 24 Nm): legs actuator.rmd-x8 · 1 alt | actuator | 4 | $420.00list price | $1,680.00 | Offers in CN only |
| 85 | MyActuator RMD-X6 (24 V, CAN, 8 Nm): arms actuator.rmd-x6 · 1 alt | actuator | 4 | $280.00list price | $1,120.00 | Offers in CN only |
| 86 | MyActuator CEM-60 (48 V, CAN, 20 Nm): 2 pelvis + 4 legs (hip and knee pitch) actuator.cem-60 · 1 alt | actuator | 6 | $190.00list price | $1,140.00 | Offers in CN only |
| 87 | SN65HVD230 3.3 V CAN transceiver board (one per ESP32 node) electronics.can-transceiver · MPN SN65HVD230 · 1 alt | electronics | 6 | unpriced | — | Offers in IN, CN only |
| 88 | 120 Ω 0.25 W termination resistor (one at each physical bus end) electronics.can-termination | electronics | 2 | unpriced | — | No offer found yet |
| 89 | 120 Ω twisted-pair bus cable for CANH/CANL (e.g. one CAT5 pair), 2 m+ cable.can-twisted-pair | cable | 1 | unpriced | — | No offer found yet |
| 90 | MyActuator USB-CAN debugging tool (actuator ID setup and tests) electronics.usb-can | electronics | 1 | unpriced | — | Offers in CN only |
| 91 | ESP32 DevKit v1: foot pressure reader (one per foot) electronics.esp32-feet | electronics | 2 | unpriced | — | Offers in CN only |
| 92 | 48 V 20 Ah Li-ion pack (960 Wh) power.battery | power | 1 | $180.00list price | $180.00 | Offers in CN only |
| 93 | 48 V 40 A balancing BMS with NTC power.bms | power | 1 | $35.00list price | $35.00 | Offers in CN only |
| 94 | XT60 female connector, 60 A (pelvis 1, legs 1) cable.xt60-female | cable | 2 | $1.20list price | $2.40 | Offers in CN only |
| Cart total · US | 1,539 | $9,947.90 | 8 lines unpriced, not in total | |||
Fabricate
Planned for a 256 mm bed- Fabricated parts
- 296
- Print time (sum)
- 460 h
- Material (sum)
- 11,556 g
- Plates · estimate
- ≈ 58
Plates is an estimate, not a slice: the package has no part footprints, so it assumes about 200 g of FDM parts per plate on a 256 mm bed, scaled by bed area (256 mm ≈ 200 g/plate). Parts larger than your bed are not detected. One printer running around the clock: about 19.2 days.
| Part | Process | Material | Qty | h / part | g / part | Profile |
|---|---|---|---|---|---|---|
Head: base-stepper-mount printed.head.base-stepper-mount | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 3 | 1.5 | 36 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 1) |
Head: center-bracket2 printed.head.center-bracket2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 3 | 1.4 | 32 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Head_Printplate.3mf plate 1) |
Head: realsense 2 printed.head.realsense-2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 1) |
Head: Screw_cylinder v3 printed.head.screw-cylinder-v3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 6 | 0.6 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Head_Printplate.3mf plate 1) |
Head: neck-driver-mount printed.head.neck-driver-mount | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 52 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Head_Printplate.3mf plate 2) |
Head: neck-stack-secondary printed.head.neck-stack-secondary | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.9 | 74 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 2) |
Head: inner-antenna-holder printed.head.inner-antenna-holder | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 2) |
Head: Head v12_new-neck v2 printed.head.head-v12-new-neck-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.8 | 80 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 3) |
Head: spidar_10mm v7 printed.head.spidar-10mm-v7 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 6 | 0.3 | 6 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 90% gyroid (Head_Printplate.3mf plate 3) |
Head: spidar_8mm v6 printed.head.spidar-8mm-v6 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 6 | 0.3 | 6 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 90% gyroid (Head_Printplate.3mf plate 3) |
Head: rear-base printed.head.rear-base | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 8.5 | 199 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 4) |
Head: front-plate printed.head.front-plate | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.9 | 91 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 4) |
Head: neck-back printed.head.neck-back | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 4.0 | 115 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 5) |
Head: mouth2 printed.head.mouth2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.2 | 63 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 5) |
Head: center-bracket printed.head.center-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.9 | 82 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 5) |
Head: temple2 printed.head.temple2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 10.8 | 241 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 6) |
Head: realsense-bracket printed.head.realsense-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.7 | 61 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 6) |
Head: GPIO_Rail_AGX printed.head.gpio-rail-agx | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.7 | 74 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 7) |
Head: base-cover printed.head.base-cover | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.3 | 88 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Head_Printplate.3mf plate 7) |
Torso: neck-chest-interface2 printed.torso.neck-chest-interface2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 6.1 | 129 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 90% gyroid (Torso_Printplate.3mf plate 1) |
Torso: Front_mid_left_rib v2 printed.torso.front-mid-left-rib-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 1) |
Torso: Front_mid_right_rib v2 printed.torso.front-mid-right-rib-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 1) |
Torso: back_left_splinesupport v3 printed.torso.back-left-splinesupport-v3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 45 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 1) |
Torso: back_right_splinesupport v4 printed.torso.back-right-splinesupport-v4 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 45 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 1) |
Torso: handle (1) printed.torso.handle-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 5.2 | 122 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Torso_Printplate.3mf plate 2) |
Torso: handle printed.torso.handle | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 5.2 | 122 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 30% gyroid (Torso_Printplate.3mf plate 2) |
Torso: left_rmd_x10mount v2 printed.torso.left-rmd-x10mount-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.0 | 70 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 2) |
Torso: right_rmdx10mount v2 printed.torso.right-rmdx10mount-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.0 | 70 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 2) |
Torso: HumanoidTorso_left-front-rib-lower v4 printed.torso.humanoidtorso-left-front-rib-lower-v4 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.3 | 51 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 3) |
Torso: HumanoidTorso_Right-front-rib-lower_Component2 v1 printed.torso.humanoidtorso-right-front-rib-lower-component2-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.3 | 51 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 3) |
Torso: Torso_ug_front-Left-shoulder_Component2 v1 printed.torso.torso-ug-front-left-shoulder-component2-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.6 | 56 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 3) |
Torso: Torso_ug_front-right-shoulder v5 printed.torso.torso-ug-front-right-shoulder-v5 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.6 | 56 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 3) |
Torso: Left_back_shoulder v5 printed.torso.left-back-shoulder-v5 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.7 | 59 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 3) |
Torso: Right_back_shoulder v11 printed.torso.right-back-shoulder-v11 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.6 | 57 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 3) |
Torso: killswitch-spine-interface printed.torso.killswitch-spine-interface | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.6 | 35 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 3) |
Torso: button-holder printed.torso.button-holder | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 14 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 3) |
Torso: back_lower_rightrib v2 printed.torso.back-lower-rightrib-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.6 | 34 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 4) |
Torso: back_lower_leftrib v2 printed.torso.back-lower-leftrib-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.6 | 34 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 4) |
Torso: right_battery_mount v3 printed.torso.right-battery-mount-v3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 4.5 | 95 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 4) |
Torso: left_battery_mount v2 printed.torso.left-battery-mount-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 4.5 | 95 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 4) |
Torso: battery-monitor-holder printed.torso.battery-monitor-holder | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 13 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 4) |
Torso: 6band (1) v1 printed.torso.6band-1-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 0.8 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 5) |
Torso: Back_middle_Strap v5 printed.torso.back-middle-strap-v5 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 4.0 | 80 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 5) |
Torso: Front_middle_Strap v4 printed.torso.front-middle-strap-v4 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.9 | 79 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 5) |
Torso: rear-right-shoulder_MIR printed.torso.rear-right-shoulder-mir | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.9 | 40 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 6) |
Torso: rear-right-shoulder printed.torso.rear-right-shoulder | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.9 | 40 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 6) |
Torso: HumanoidTorso_lumbar-strap v1 printed.torso.humanoidtorso-lumbar-strap-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.1 | 64 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 6) |
Torso: HumanoidTorso_naval-strap (1) v1 printed.torso.humanoidtorso-naval-strap-1-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.9 | 39 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 70% gyroid (Torso_Printplate.3mf plate 6) |
Torso: head-power-supply-bracket printed.torso.head-power-supply-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 13 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Torso_Printplate.3mf plate 6) |
Pelvis: Hip_CEMmount_front_Top printed.pelvic-girdle.hip-cemmount-front-top | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 6.5 | 168 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 1) |
Pelvis: lumbare printed.pelvic-girdle.lumbare | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.3 | 86 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 1) |
Pelvis: Hip_CEMmount_front_down printed.pelvic-girdle.hip-cemmount-front-down | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 6.4 | 167 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 1) |
Pelvis: HumanoidPelvicGirdle v11_naval (1) v2 printed.pelvic-girdle.humanoidpelvicgirdle-v11-naval-1-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.7 | 43 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 1) |
Pelvis: Component2 printed.pelvic-girdle.component2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 28 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Component2(Mirror) printed.pelvic-girdle.component2-mirror | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 28 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Lumbar Mounts printed.pelvic-girdle.lumbar-mounts | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 11.0 | 299 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_rmd_spacer2 printed.pelvic-girdle.hip-rmd-spacer2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 22 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_rmd_spacer1 printed.pelvic-girdle.hip-rmd-spacer1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 22 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_profilelock2 printed.pelvic-girdle.hip-profilelock2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_profilelock1 printed.pelvic-girdle.hip-profilelock1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_rmdmount2 printed.pelvic-girdle.hip-rmdmount2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_rmd_mount4 printed.pelvic-girdle.hip-rmd-mount4 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_rmdmount3 printed.pelvic-girdle.hip-rmdmount3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Hip_rmdmount1 printed.pelvic-girdle.hip-rmdmount1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 2) |
Pelvis: Groin_front printed.pelvic-girdle.groin-front | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: butt_centr1 printed.pelvic-girdle.butt-centr1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 31 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: Bearing_holder2 printed.pelvic-girdle.bearing-holder2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 21 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: HumanoidPelvicGirdle v11_hips-front-mount v2 printed.pelvic-girdle.humanoidpelvicgirdle-v11-hips-front-mount-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: Groin centre printed.pelvic-girdle.groin-centre | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 14 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: HumanoidPelvicGirdle v11_front-bearing-strap (1) v2 printed.pelvic-girdle.humanoidpelvicgirdle-v11-front-bearing-strap-1-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: Butt_centre2 printed.pelvic-girdle.butt-centre2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: Back printed.pelvic-girdle.back | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 8.5 | 231 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 3) |
Pelvis: Bearing Holder1 printed.pelvic-girdle.bearing-holder1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 21 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 4) |
Pelvis: Hip_roll_R2 printed.pelvic-girdle.hip-roll-r2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 56 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 4) |
Pelvis: Hip_roll_R1 printed.pelvic-girdle.hip-roll-r1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 56 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 4) |
Pelvis: Hip_roll_L2 printed.pelvic-girdle.hip-roll-l2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 56 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 4) |
Pelvis: Hip_roll_l1 printed.pelvic-girdle.hip-roll-l1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 56 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Pelvis_Printplate.3mf plate 4) |
Left arm: bicep-rotational-cuff-second-motor-bracket(Mirror) (1) printed.left-arm.bicep-rotational-cuff-second-motor-bracket-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 26 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: yaw-waist-adapter-motor-exal_MIR1 (5)(Mirror) (1) printed.left-arm.yaw-waist-adapter-motor-exal-mir1-5-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 30 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: yaw-waist-adapter-motor-exal_MIR1(Mirror) (1) printed.left-arm.yaw-waist-adapter-motor-exal-mir1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 30 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: shoulder-front(Mirror) (1) printed.left-arm.shoulder-front-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: shoulder-cap(Mirror) (1) printed.left-arm.shoulder-cap-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.4 | 37 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: shoulder-front-bearing-adapter(Mirror) (1) printed.left-arm.shoulder-front-bearing-adapter-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.6 | 42 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: elbow-hangar(Mirror) (1) printed.left-arm.elbow-hangar-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: elbow-hangar1(Mirror) (1) printed.left-arm.elbow-hangar1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: elbow-bridge-rear (1)(Mirror) (1) printed.left-arm.elbow-bridge-rear-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 2 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: shoulder-roll-al-mot_MIR1 (1)(Mirror) (1) printed.left-arm.shoulder-roll-al-mot-mir1-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: elbow-bridge-rear(Mirror) (1) printed.left-arm.elbow-bridge-rear-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 2 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: bicep-shoulder-bracket-exal (1)(Mirror) (1) printed.left-arm.bicep-shoulder-bracket-exal-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: bicep-shoulder-bracket-exal (2)(Mirror) (1) printed.left-arm.bicep-shoulder-bracket-exal-2-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: bicep-shoulder-bracket-exal (3)(Mirror) (1) printed.left-arm.bicep-shoulder-bracket-exal-3-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: bicep-shoulder-bracket-exal(Mirror) (1) printed.left-arm.bicep-shoulder-bracket-exal-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: shoulder-roll-al-mot_MIR1 (2)(Mirror) (1) printed.left-arm.shoulder-roll-al-mot-mir1-2-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: shoulder-roll-al-mot_MIR1 (3)(Mirror) (1) printed.left-arm.shoulder-roll-al-mot-mir1-3-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: shoulder-roll-al-mot_MIR1(Mirror) (1) printed.left-arm.shoulder-roll-al-mot-mir1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 1) |
Left arm: straight-tendon(Mirror) (1) printed.left-arm.straight-tendon-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: arm-cuff-bicep-bracket(Mirror) (1) printed.left-arm.arm-cuff-bicep-bracket-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.3 | 33 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: bicep-rear-motor-adapter(Mirror) (1) printed.left-arm.bicep-rear-motor-adapter-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: shoulder-motor-bicep-rotor-bracket(Mirror) (1) printed.left-arm.shoulder-motor-bicep-rotor-bracket-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: forearm-elbow-motor-bracket-inner(Mirror) (1) printed.left-arm.forearm-elbow-motor-bracket-inner-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: forearm-elbow-motor-bracket-inner2(Mirror) (1) printed.left-arm.forearm-elbow-motor-bracket-inner2-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: second-forearm-motor-strap(Mirror) (1) printed.left-arm.second-forearm-motor-strap-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: shoulder-ex-al-interface(Mirror) (1) printed.left-arm.shoulder-ex-al-interface-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: elbow-rear-hanger(Mirror) (1) printed.left-arm.elbow-rear-hanger-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 7 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: shoulder-ex-al-interface (1)(Mirror) (1) printed.left-arm.shoulder-ex-al-interface-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: shoulder-ex-al-interface (2)(Mirror) (1) printed.left-arm.shoulder-ex-al-interface-2-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: elbow-rear-hanger (1)(Mirror) (1) printed.left-arm.elbow-rear-hanger-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 7 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: front-bearing-adapter-shoulder(Mirror) (1) printed.left-arm.front-bearing-adapter-shoulder-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: bicep(Mirror) (1) printed.left-arm.bicep-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.2 | 4 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: power-mount-arm(Mirror) (1) printed.left-arm.power-mount-arm-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 8 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 2) |
Left arm: yaw-cap(Mirror) (1) printed.left-arm.yaw-cap-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 3) |
Left arm: multiplex-stack-flat(Mirror) (1) printed.left-arm.multiplex-stack-flat-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 3) |
Left arm: top-bracket-servo-strap (1)(Mirror) (1) printed.left-arm.top-bracket-servo-strap-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 3) |
Left arm: top-bracket-servo-strap(Mirror) (1) printed.left-arm.top-bracket-servo-strap-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 3) |
Left arm: fan-mount(Mirror) (1) printed.left-arm.fan-mount-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 6 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 3) |
Left arm: bicep-motor-mate(Mirror) (1) printed.left-arm.bicep-motor-mate-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 3) |
Left arm: fore-arm-bicep-motor-attatch(Mirror) (1) printed.left-arm.fore-arm-bicep-motor-attatch-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 21 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Left_arm_Printplate.3mf plate 3) |
Right arm: bicep-rotational-cuff-second-motor-bracket printed.right-arm.bicep-rotational-cuff-second-motor-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 26 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: yaw-waist-adapter-motor-exal_MIR1 printed.right-arm.yaw-waist-adapter-motor-exal-mir1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 30 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: yaw-waist-adapter-motor-exal_MIR1 (5) printed.right-arm.yaw-waist-adapter-motor-exal-mir1-5 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 30 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: shoulder-front printed.right-arm.shoulder-front | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: shoulder-roll-al-mot_MIR1 (3) printed.right-arm.shoulder-roll-al-mot-mir1-3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: shoulder-roll-al-mot_MIR1 (2) printed.right-arm.shoulder-roll-al-mot-mir1-2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: shoulder-roll-al-mot_MIR1 (1) printed.right-arm.shoulder-roll-al-mot-mir1-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: shoulder-roll-al-mot_MIR1 printed.right-arm.shoulder-roll-al-mot-mir1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: shoulder-cap printed.right-arm.shoulder-cap | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.4 | 37 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: shoulder-front-bearing-adapter printed.right-arm.shoulder-front-bearing-adapter | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.6 | 42 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: elbow-hangar1 printed.right-arm.elbow-hangar1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: elbow-hangar printed.right-arm.elbow-hangar | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: elbow-bridge-rear printed.right-arm.elbow-bridge-rear | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 2 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: elbow-bridge-rear (1) printed.right-arm.elbow-bridge-rear-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 2 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: bicep-shoulder-bracket-exal (1) printed.right-arm.bicep-shoulder-bracket-exal-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: bicep-shoulder-bracket-exal (2) printed.right-arm.bicep-shoulder-bracket-exal-2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: bicep-shoulder-bracket-exal (3) printed.right-arm.bicep-shoulder-bracket-exal-3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: bicep-shoulder-bracket-exal printed.right-arm.bicep-shoulder-bracket-exal | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 9 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 1) |
Right arm: straight-tendon printed.right-arm.straight-tendon | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: arm-cuff-bicep-bracket printed.right-arm.arm-cuff-bicep-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.2 | 33 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: bicep-rear-motor-adapter printed.right-arm.bicep-rear-motor-adapter | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: shoulder-motor-bicep-rotor-bracket printed.right-arm.shoulder-motor-bicep-rotor-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: forearm-elbow-motor-bracket-inner printed.right-arm.forearm-elbow-motor-bracket-inner | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: forearm-elbow-motor-bracket-inner2 printed.right-arm.forearm-elbow-motor-bracket-inner2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: second-forearm-motor-strap printed.right-arm.second-forearm-motor-strap | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: elbow-rear-hanger (1) printed.right-arm.elbow-rear-hanger-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 7 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: elbow-rear-hanger printed.right-arm.elbow-rear-hanger | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 7 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: shoulder-ex-al-interface (2) printed.right-arm.shoulder-ex-al-interface-2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: shoulder-ex-al-interface (1) printed.right-arm.shoulder-ex-al-interface-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: shoulder-ex-al-interface printed.right-arm.shoulder-ex-al-interface | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: front-bearing-adapter-shoulder printed.right-arm.front-bearing-adapter-shoulder | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: power-mount-arm printed.right-arm.power-mount-arm | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 8 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: bicep printed.right-arm.bicep | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 4 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 2) |
Right arm: multiplex-stack-flat printed.right-arm.multiplex-stack-flat | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 19 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 3) |
Right arm: top-bracket-servo-strap (1) printed.right-arm.top-bracket-servo-strap-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.7 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 3) |
Right arm: top-bracket-servo-strap printed.right-arm.top-bracket-servo-strap | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.7 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 3) |
Right arm: fan-mount printed.right-arm.fan-mount | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.3 | 6 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 3) |
Right arm: bicep-motor-mate printed.right-arm.bicep-motor-mate | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 23 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 3) |
Right arm: fore-arm-bicep-motor-attatch printed.right-arm.fore-arm-bicep-motor-attatch | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 3) |
Right arm: yaw-cap printed.right-arm.yaw-cap | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 14 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 35% gyroid (Right_arm_Printplate.3mf plate 3) |
Left leg: Thigh_BUSH v3 printed.left-leg.thigh-bush-v3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 3.1 | 78 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 1) |
Left leg: HumanoidPelvicGirdle v11_hip-roll-al-mot_MIR2 (1) v2 printed.left-leg.humanoidpelvicgirdle-v11-hip-roll-al-mot-mir2-1-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 0.8 | 19 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 1) |
Left leg: left_thigh_connector printed.left-leg.left-thigh-connector | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 13 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 1) |
Left leg: Thigh_Component3 v2 printed.left-leg.thigh-component3-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 5.2 | 131 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 1) |
Left leg: Thigh_Component1 v8 printed.left-leg.thigh-component1-v8 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 5.1 | 127 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 1) |
Left leg: Thigh_left_cemmount printed.left-leg.thigh-left-cemmount | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 4.9 | 122 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 1) |
Left leg: basis_left printed.left-leg.basis-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.9 | 74 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: ankle-thick printed.left-leg.ankle-thick | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.4 | 62 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: bearingstrap (1) printed.left-leg.bearingstrap-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 26 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: calf-motor-driver-ext printed.left-leg.calf-motor-driver-ext | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 1.3 | 32 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: heel-topleft printed.left-leg.heel-topleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 24 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: knee-strap-second-test (1) printed.left-leg.knee-strap-second-test-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 25 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: heel-top_MIRleft printed.left-leg.heel-top-mirleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 24 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: knee-strap-second-test printed.left-leg.knee-strap-second-test | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 25 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: bearingstrap printed.left-leg.bearingstrap | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 26 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: foot-imu-strap printed.left-leg.foot-imu-strap | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 2 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 2) |
Left leg: heel-bracket_left printed.left-leg.heel-bracket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.4 | 60 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: heel-bracketleft printed.left-leg.heel-bracketleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.3 | 57 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: conjstraint-knee-test-oute printed.left-leg.conjstraint-knee-test-oute | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.8 | 69 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: conjstraint-knee-test-oute_MIR printed.left-leg.conjstraint-knee-test-oute-mir | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.8 | 70 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: 6band (5) printed.left-leg.6band-5 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.2 | 30 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: heel-roller printed.left-leg.heel-roller | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 3 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: motor-calf-exal-mount printed.left-leg.motor-calf-exal-mount | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 4 | 0.4 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: bearingstrap-inner-thigh(Mirror) (1) printed.left-leg.bearingstrap-inner-thigh-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: thigh-bracket(Mirror) (1) printed.left-leg.thigh-bracket-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.6 | 41 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 3) |
Left leg: double-bracket printed.left-leg.double-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.8 | 73 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: HumanoidLeftLeg v22 (1)_ankle-side-bracket123 v2 printed.left-leg.humanoidleftleg-v22-1-ankle-side-bracket123-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: ankle-motor-driver-bracketleft printed.left-leg.ankle-motor-driver-bracketleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: ankle-motor-driver-bracket_left printed.left-leg.ankle-motor-driver-bracket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: calf-lower-bracket_left printed.left-leg.calf-lower-bracket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: calf-lower-bracket printed.left-leg.calf-lower-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: ankle-side-bracket printed.left-leg.ankle-side-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: bearing-sensor-adapter printed.left-leg.bearing-sensor-adapter | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 0.1 | 3 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: double-bracket-10deg_MIR_MIR_MIR(Mirror) (1) printed.left-leg.double-bracket-10deg-mir-mir-mir-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.9 | 76 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 4) |
Left leg: Toe v1 printed.left-leg.toe-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 6.2 | 156 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 5) |
Left leg: multiplex-stack printed.left-leg.multiplex-stack | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 5) |
Left leg: calf-skin_flip printed.left-leg.calf-skin-flip | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.8 | 46 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 5) |
Left leg: bearing-sensor-adapter-arm printed.left-leg.bearing-sensor-adapter-arm | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 0.3 | 7 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 5) |
Left leg: knee-lock-2 printed.left-leg.knee-lock-2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.7 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 5) |
Left leg: calf-skin printed.left-leg.calf-skin | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.8 | 46 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 5) |
Left leg: knee-lock-2-b printed.left-leg.knee-lock-2-b | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.7 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 5) |
Left leg: new-heel-opposing printed.left-leg.new-heel-opposing | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.7 | 72 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 6) |
Left leg: tie-rod-ankle-brackket_left1 printed.left-leg.tie-rod-ankle-brackket-left1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.2 | 58 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 6) |
Left leg: tie-rod-ankle-brackket_left printed.left-leg.tie-rod-ankle-brackket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.2 | 58 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 6) |
Left leg: flank(Mirror) (1) printed.left-leg.flank-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.4 | 63 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 6) |
Left leg: flank (1)(Mirror) (1) printed.left-leg.flank-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.4 | 63 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 6) |
Left leg: calf-cover printed.left-leg.calf-cover | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 2.4 | 57 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 7) |
Left leg: flank-front (1)(Mirror) (1) printed.left-leg.flank-front-1-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.3 | 120 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 8) |
Left leg: flank-front(Mirror) (1) printed.left-leg.flank-front-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.3 | 120 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 8) |
Left leg: flank-front-flipped(Mirror) (1) printed.left-leg.flank-front-flipped-mirror-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 3.1 | 80 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Left_leg_Printplates.3mf plate 9) |
Right leg: CEM60_thigh_Right_Thigh_Component1 v8(Mirror) v1 printed.right-leg.cem60-thigh-right-thigh-component1-v8-mirror-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 5.1 | 127 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 1) |
Right leg: CEM-right-mount printed.right-leg.cem-right-mount | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 4.9 | 122 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 1) |
Right leg: Thigh_BUSH v3 printed.right-leg.thigh-bush-v3 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 3.1 | 78 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 1) |
Right leg: CEM60_thigh_Left_Thigh_Component3 v2(Mirror) v1 printed.right-leg.cem60-thigh-left-thigh-component3-v2-mirror-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 5.2 | 131 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 1) |
Right leg: HumanoidPelvicGirdle v11_hip-roll-al-mot_MIR2 (1) v2 printed.right-leg.humanoidpelvicgirdle-v11-hip-roll-al-mot-mir2-1-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 0.8 | 19 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 1) |
Right leg: HumanoidLeftLeg_CEM60_Component216_Component2 v1 printed.right-leg.humanoidleftleg-cem60-component216-component2-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.5 | 13 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 1) |
Right leg: basis_left printed.right-leg.basis-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.9 | 73 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: ankle-thick printed.right-leg.ankle-thick | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.4 | 62 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: bearingstrap (1) printed.right-leg.bearingstrap-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 26 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: calf-motor-driver-ext printed.right-leg.calf-motor-driver-ext | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 1.3 | 32 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: heel-topleft printed.right-leg.heel-topleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 24 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: knee-strap-second-test (1) printed.right-leg.knee-strap-second-test-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 25 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: heel-top_MIRleft printed.right-leg.heel-top-mirleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.9 | 24 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: knee-strap-second-test printed.right-leg.knee-strap-second-test | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 25 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: bearingstrap printed.right-leg.bearingstrap | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 26 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 2) |
Right leg: heel-bracket_left printed.right-leg.heel-bracket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.4 | 60 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: heel-bracketleft printed.right-leg.heel-bracketleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.3 | 58 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: conjstraint-knee-test-oute printed.right-leg.conjstraint-knee-test-oute | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.8 | 70 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: conjstraint-knee-test-oute_MIR printed.right-leg.conjstraint-knee-test-oute-mir | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.9 | 70 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: Thigh bracket v2 printed.right-leg.thigh-bracket-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.7 | 41 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 50% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: bearingstrap-inner-thigh printed.right-leg.bearingstrap-inner-thigh | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.1 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: 6band (5) printed.right-leg.6band-5 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.2 | 31 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: heel-roller printed.right-leg.heel-roller | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.1 | 3 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: motor-calf-exal-mount printed.right-leg.motor-calf-exal-mount | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 4 | 0.5 | 11 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 3) |
Right leg: double-bracket-10deg_MIR_MIR_MIR printed.right-leg.double-bracket-10deg-mir-mir-mir | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.9 | 76 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: double-bracket printed.right-leg.double-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.8 | 73 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: HumanoidLeftLeg v22 (1)_ankle-side-bracket123 v2 printed.right-leg.humanoidleftleg-v22-1-ankle-side-bracket123-v2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: ankle-motor-driver-bracketleft printed.right-leg.ankle-motor-driver-bracketleft | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: ankle-motor-driver-bracket_left printed.right-leg.ankle-motor-driver-bracket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 15 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: calf-lower-bracket_left printed.right-leg.calf-lower-bracket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: calf-lower-bracket printed.right-leg.calf-lower-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.0 | 27 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: ankle-side-bracket printed.right-leg.ankle-side-bracket | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.6 | 17 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: bearing-sensor-adapter printed.right-leg.bearing-sensor-adapter | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 0.1 | 3 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 4) |
Right leg: Toe v1 printed.right-leg.toe-v1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 6.2 | 156 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 5) |
Right leg: multiplex-stack printed.right-leg.multiplex-stack | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.8 | 20 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 5) |
Right leg: calf-skin_flip printed.right-leg.calf-skin-flip | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.8 | 46 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 5) |
Right leg: bearing-sensor-adapter-arm printed.right-leg.bearing-sensor-adapter-arm | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 0.3 | 7 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 5) |
Right leg: knee-lock-2 printed.right-leg.knee-lock-2 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.7 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 5) |
Right leg: calf-skin printed.right-leg.calf-skin | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 1.8 | 46 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 5) |
Right leg: knee-lock-2-b printed.right-leg.knee-lock-2-b | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 0.7 | 16 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 5) |
Right leg: flank printed.right-leg.flank | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.3 | 63 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 6) |
Right leg: flank (1) printed.right-leg.flank-1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.3 | 63 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 6) |
Right leg: new-heel-opposing printed.right-leg.new-heel-opposing | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.6 | 71 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 6) |
Right leg: tie-rod-ankle-brackket_left1 printed.right-leg.tie-rod-ankle-brackket-left1 | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 57 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 6) |
Right leg: tie-rod-ankle-brackket_left printed.right-leg.tie-rod-ankle-brackket-left | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.1 | 58 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 6) |
Right leg: calf-cover printed.right-leg.calf-cover | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 2.4 | 57 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 7) |
Right leg: flank-front printed.right-leg.flank-front | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 2 | 3.3 | 120 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 8) |
Right leg: flank-front-flipped printed.right-leg.flank-front-flipped | FDM | PLA (plates validated in PLA on a Bambu P1S; PETG/ABS preferred, CF-PETG or nylon for leg brackets) | 1 | 2.4 | 73 | Bambu P1S, 0.4 mm nozzle, 0.2 mm layers, 4 walls, 40% gyroid (Right_leg_Printplate.3mf plate 9) |
Feet: foot assembly from foot-v3.stp (TPU 95-98A for the yellow sole parts, PLA for the rest) printed.feet.foot | FDM | TPU 95-98A Shore (sole/damping parts) + PLA at >=80% rectilinear infill, >=5 walls, >=5 top/bottom layers | 2 | — | — | source |
Assemble
Every step ends in a check- Steps
- 40
- Subassemblies
- 11
- Hands-on time (sum)
- 78 h 15 min
- Critical path
- 32 h
- Your progress · this device
- —
6 steps have no time estimate; times above are lower bounds.
Steps, in build order
- Fabrication01
Calibrate the printer and print a fit test
Level the bed, calibrate flow and run a calibration object. Load the repo's .3mf plates as they are: layer height, walls, gyroid infill and per-part infill overrides are embedded and the print guide says not to override them unless you are sure. PLA is what the plates were validated with; the printables README prefers PETG or ABS for a robot you will load, and CF-PETG or nylon for leg brackets.
CHECKA 608ZZ bearing presses into a printed seat by hand with no play (bearing fits ±0.1 mm, mating faces ±0.2 mm per the printing guide).- Parts in
- —
- Tools
- FDM printer, 220x220x250 mm minimum (validated on a Bambu Lab P1S), Calipers, Bambu Studio or PrusaSlicer
- Torque
- —
- Time
- 1 h 30 min
- After
- Start
- Source
- github.com
- 02
Cut extrusions and pre-load T-nuts
Order 20x20 slot-6 extrusion pre-cut to the BOM lengths (Misumi recommended) or cut and deburr it yourself. Label each length by subassembly. Slide the T-nuts in before any frame is closed: 155 go into the torso, 64 into the arms, 28 into the pelvis.
CHECK48 pieces: 1x85, 12x100, 16x150, 11x200, 2x250, 3x300, 1x350, 2x400 mm, each within 0.5 mm.- Parts in
- 20x20 slot-6 aluminium extrusion, 85 mm (pelvic 1)structure.extrusion-2020-85
- 20x20 slot-6 aluminium extrusion, 100 mm (torso 6, arms 4, legs 2)structure.extrusion-2020-100
- 20x20 slot-6 aluminium extrusion, 150 mm (torso 8, arms 2, pelvic 2, legs 4)structure.extrusion-2020-150
- 20x20 slot-6 aluminium extrusion, 200 mm (torso 10, pelvic 1)structure.extrusion-2020-200
- 20x20 slot-6 aluminium extrusion, 250 mm (legs 2)structure.extrusion-2020-250
- 20x20 slot-6 aluminium extrusion, 300 mm (torso 1, legs 2)structure.extrusion-2020-300
- 20x20 slot-6 aluminium extrusion, 350 mm (torso 1)structure.extrusion-2020-350
- 20x20 slot-6 aluminium extrusion, 400 mm (legs 2)structure.extrusion-2020-400
- Extrusion T-nut M4, slot 6 (torso 155, arms 64, pelvic 28)fastener.tnut-m4-slot6
- Tools
- Allen key set M3-M8, Metric spanner set, Deburring tool
- Torque
- —
- Time
- 2 h
- After
- Start
- Source
- github.com
- 03
Set every actuator's CAN ID before installing it
Safety · human-verified requiredPower one actuator at a time on the bench. Assign its ID with opcode 0x79, power-cycle to store it, and read it back with the status command 0x9A. Use the IDs the docs use: waist 10-12, right arm 21-25, left arm 31-35, left hip/knee 40/43, right hip/knee 50/53. Write the ID on the housing.
CHECKEvery actuator answers 0x9A at its assigned ID with no other actuator connected, and no two actuators share an ID.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- MyActuator RMD-X10 (24-48 V, CAN, 50 Nm): 2 torso waist + 2 pelvisactuator.rmd-x10
- MyActuator RMD-X8 (24-48 V, CAN, 24 Nm): legsactuator.rmd-x8
- MyActuator RMD-X6 (24 V, CAN, 8 Nm): armsactuator.rmd-x6
- MyActuator CEM-60 (48 V, CAN, 20 Nm): 2 pelvis + 4 legs (hip and knee pitch)actuator.cem-60
- MyActuator USB-CAN debugging tool (actuator ID setup and tests)electronics.usb-can
- Tools
- MyActuator USB-CAN tool, Bench supply 24-48 V with current limit, myactuator-can
- Torque
- —
- Time
- 2 h
- After
- Start
- Source
- github.com
- 04
Print the head plates (7 plates, ~67 h)
Print all seven plates of Head_Printplate.3mf: stepper mounts and brackets for the six-leg neck, the head shell and the RealSense mount. Sliced with the embedded settings: 67.1 h and about 1.6 kg of PLA.
CHECK38 parts off the bed; every part on the plate list is present and the three stepper mounts are identical.- Parts in
- Head: base-stepper-mountprinted.head.base-stepper-mount
- Head: center-bracket2printed.head.center-bracket2
- Head: realsense 2printed.head.realsense-2
- Head: Screw_cylinder v3printed.head.screw-cylinder-v3
- Head: neck-driver-mountprinted.head.neck-driver-mount
- Head: neck-stack-secondaryprinted.head.neck-stack-secondary
- Head: inner-antenna-holderprinted.head.inner-antenna-holder
- Head: Head v12_new-neck v2printed.head.head-v12-new-neck-v2
- Head: spidar_10mm v7printed.head.spidar-10mm-v7
- Head: spidar_8mm v6printed.head.spidar-8mm-v6
- Head: rear-baseprinted.head.rear-base
- Head: front-plateprinted.head.front-plate
- Head: neck-backprinted.head.neck-back
- Head: mouth2printed.head.mouth2
- Head: center-bracketprinted.head.center-bracket
- Head: temple2printed.head.temple2
- Head: realsense-bracketprinted.head.realsense-bracket
- Head: GPIO_Rail_AGXprinted.head.gpio-rail-agx
- Head: base-coverprinted.head.base-cover
- Tools
- FDM printer
- Torque
- —
- Time
- —
- After
- 01
- Source
- github.com
- 05
Print the torso plates (6 plates, ~78 h)
Print Torso_Printplate.3mf: ribs, spline supports, RMD-X10 waist mounts, neck-chest interface and handles. Sliced: 78.1 h, about 1.7 kg.
CHECK31 parts; the left and right RMD-X10 mounts seat on an actuator face without forcing.- Parts in
- Torso: neck-chest-interface2printed.torso.neck-chest-interface2
- Torso: Front_mid_left_rib v2printed.torso.front-mid-left-rib-v2
- Torso: Front_mid_right_rib v2printed.torso.front-mid-right-rib-v2
- Torso: back_left_splinesupport v3printed.torso.back-left-splinesupport-v3
- Torso: back_right_splinesupport v4printed.torso.back-right-splinesupport-v4
- Torso: handle (1)printed.torso.handle-1
- Torso: handleprinted.torso.handle
- Torso: left_rmd_x10mount v2printed.torso.left-rmd-x10mount-v2
- Torso: right_rmdx10mount v2printed.torso.right-rmdx10mount-v2
- Torso: HumanoidTorso_left-front-rib-lower v4printed.torso.humanoidtorso-left-front-rib-lower-v4
- Torso: HumanoidTorso_Right-front-rib-lower_Component2 v1printed.torso.humanoidtorso-right-front-rib-lower-component2-v1
- Torso: Torso_ug_front-Left-shoulder_Component2 v1printed.torso.torso-ug-front-left-shoulder-component2-v1
- Torso: Torso_ug_front-right-shoulder v5printed.torso.torso-ug-front-right-shoulder-v5
- Torso: Left_back_shoulder v5printed.torso.left-back-shoulder-v5
- Torso: Right_back_shoulder v11printed.torso.right-back-shoulder-v11
- Torso: killswitch-spine-interfaceprinted.torso.killswitch-spine-interface
- Torso: button-holderprinted.torso.button-holder
- Torso: back_lower_rightrib v2printed.torso.back-lower-rightrib-v2
- Torso: back_lower_leftrib v2printed.torso.back-lower-leftrib-v2
- Torso: right_battery_mount v3printed.torso.right-battery-mount-v3
- Torso: left_battery_mount v2printed.torso.left-battery-mount-v2
- Torso: battery-monitor-holderprinted.torso.battery-monitor-holder
- Torso: 6band (1) v1printed.torso.6band-1-v1
- Torso: Back_middle_Strap v5printed.torso.back-middle-strap-v5
- Torso: Front_middle_Strap v4printed.torso.front-middle-strap-v4
- Torso: rear-right-shoulder_MIRprinted.torso.rear-right-shoulder-mir
- Torso: rear-right-shoulderprinted.torso.rear-right-shoulder
- Torso: HumanoidTorso_lumbar-strap v1printed.torso.humanoidtorso-lumbar-strap-v1
- Torso: HumanoidTorso_naval-strap (1) v1printed.torso.humanoidtorso-naval-strap-1-v1
- Torso: head-power-supply-bracketprinted.torso.head-power-supply-bracket
- Tools
- FDM printer
- Torque
- —
- Time
- —
- After
- 01
- Source
- github.com
- 06
Print the pelvis plates (4 plates, ~58 h)
Print Pelvis_Printplate.3mf: CEM-60 hip mounts, RMD mounts and spacers, profile locks, lumbar mounts, bearing holders and the groin/butt shells. Sliced: 57.8 h, about 1.5 kg.
CHECK28 parts; bearing holders take a 608ZZ by hand press with no play.- Parts in
- Pelvis: Hip_CEMmount_front_Topprinted.pelvic-girdle.hip-cemmount-front-top
- Pelvis: lumbareprinted.pelvic-girdle.lumbare
- Pelvis: Hip_CEMmount_front_downprinted.pelvic-girdle.hip-cemmount-front-down
- Pelvis: HumanoidPelvicGirdle v11_naval (1) v2printed.pelvic-girdle.humanoidpelvicgirdle-v11-naval-1-v2
- Pelvis: Component2printed.pelvic-girdle.component2
- Pelvis: Component2(Mirror)printed.pelvic-girdle.component2-mirror
- Pelvis: Lumbar Mountsprinted.pelvic-girdle.lumbar-mounts
- Pelvis: Hip_rmd_spacer2printed.pelvic-girdle.hip-rmd-spacer2
- Pelvis: Hip_rmd_spacer1printed.pelvic-girdle.hip-rmd-spacer1
- Pelvis: Hip_profilelock2printed.pelvic-girdle.hip-profilelock2
- Pelvis: Hip_profilelock1printed.pelvic-girdle.hip-profilelock1
- Pelvis: Hip_rmdmount2printed.pelvic-girdle.hip-rmdmount2
- Pelvis: Hip_rmd_mount4printed.pelvic-girdle.hip-rmd-mount4
- Pelvis: Hip_rmdmount3printed.pelvic-girdle.hip-rmdmount3
- Pelvis: Hip_rmdmount1printed.pelvic-girdle.hip-rmdmount1
- Pelvis: Groin_frontprinted.pelvic-girdle.groin-front
- Pelvis: butt_centr1printed.pelvic-girdle.butt-centr1
- Pelvis: Bearing_holder2printed.pelvic-girdle.bearing-holder2
- Pelvis: HumanoidPelvicGirdle v11_hips-front-mount v2printed.pelvic-girdle.humanoidpelvicgirdle-v11-hips-front-mount-v2
- Pelvis: Groin centreprinted.pelvic-girdle.groin-centre
- Pelvis: HumanoidPelvicGirdle v11_front-bearing-strap (1) v2printed.pelvic-girdle.humanoidpelvicgirdle-v11-front-bearing-strap-1-v2
- Pelvis: Butt_centre2printed.pelvic-girdle.butt-centre2
- Pelvis: Backprinted.pelvic-girdle.back
- Pelvis: Bearing Holder1printed.pelvic-girdle.bearing-holder1
- Pelvis: Hip_roll_R2printed.pelvic-girdle.hip-roll-r2
- Pelvis: Hip_roll_R1printed.pelvic-girdle.hip-roll-r1
- Pelvis: Hip_roll_L2printed.pelvic-girdle.hip-roll-l2
- Pelvis: Hip_roll_l1printed.pelvic-girdle.hip-roll-l1
- Tools
- FDM printer
- Torque
- —
- Time
- —
- After
- 01
- Source
- github.com
- 07
Print both arms (3 plates each, ~53 h)
Print Left_arm_Printplate.3mf and Right_arm_Printplate.3mf (26.8 h and 26.4 h, about 0.7 kg each). Keep each arm's parts bagged and labelled; left and right parts are not all mirror copies.
CHECK40 parts per arm, bagged by side.- Parts in
- Left arm: bicep-rotational-cuff-second-motor-bracket(Mirror) (1)printed.left-arm.bicep-rotational-cuff-second-motor-bracket-mirror-1
- Left arm: yaw-waist-adapter-motor-exal_MIR1 (5)(Mirror) (1)printed.left-arm.yaw-waist-adapter-motor-exal-mir1-5-mirror-1
- Left arm: yaw-waist-adapter-motor-exal_MIR1(Mirror) (1)printed.left-arm.yaw-waist-adapter-motor-exal-mir1-mirror-1
- Left arm: shoulder-front(Mirror) (1)printed.left-arm.shoulder-front-mirror-1
- Left arm: shoulder-cap(Mirror) (1)printed.left-arm.shoulder-cap-mirror-1
- Left arm: shoulder-front-bearing-adapter(Mirror) (1)printed.left-arm.shoulder-front-bearing-adapter-mirror-1
- Left arm: elbow-hangar(Mirror) (1)printed.left-arm.elbow-hangar-mirror-1
- Left arm: elbow-hangar1(Mirror) (1)printed.left-arm.elbow-hangar1-mirror-1
- Left arm: elbow-bridge-rear (1)(Mirror) (1)printed.left-arm.elbow-bridge-rear-1-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1 (1)(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-1-mirror-1
- Left arm: elbow-bridge-rear(Mirror) (1)printed.left-arm.elbow-bridge-rear-mirror-1
- Left arm: bicep-shoulder-bracket-exal (1)(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-1-mirror-1
- Left arm: bicep-shoulder-bracket-exal (2)(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-2-mirror-1
- Left arm: bicep-shoulder-bracket-exal (3)(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-3-mirror-1
- Left arm: bicep-shoulder-bracket-exal(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1 (2)(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-2-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1 (3)(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-3-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-mirror-1
- Left arm: straight-tendon(Mirror) (1)printed.left-arm.straight-tendon-mirror-1
- Left arm: arm-cuff-bicep-bracket(Mirror) (1)printed.left-arm.arm-cuff-bicep-bracket-mirror-1
- Left arm: bicep-rear-motor-adapter(Mirror) (1)printed.left-arm.bicep-rear-motor-adapter-mirror-1
- Left arm: shoulder-motor-bicep-rotor-bracket(Mirror) (1)printed.left-arm.shoulder-motor-bicep-rotor-bracket-mirror-1
- Left arm: forearm-elbow-motor-bracket-inner(Mirror) (1)printed.left-arm.forearm-elbow-motor-bracket-inner-mirror-1
- Left arm: forearm-elbow-motor-bracket-inner2(Mirror) (1)printed.left-arm.forearm-elbow-motor-bracket-inner2-mirror-1
- Left arm: second-forearm-motor-strap(Mirror) (1)printed.left-arm.second-forearm-motor-strap-mirror-1
- Left arm: shoulder-ex-al-interface(Mirror) (1)printed.left-arm.shoulder-ex-al-interface-mirror-1
- Left arm: elbow-rear-hanger(Mirror) (1)printed.left-arm.elbow-rear-hanger-mirror-1
- Left arm: shoulder-ex-al-interface (1)(Mirror) (1)printed.left-arm.shoulder-ex-al-interface-1-mirror-1
- Left arm: shoulder-ex-al-interface (2)(Mirror) (1)printed.left-arm.shoulder-ex-al-interface-2-mirror-1
- Left arm: elbow-rear-hanger (1)(Mirror) (1)printed.left-arm.elbow-rear-hanger-1-mirror-1
- Left arm: front-bearing-adapter-shoulder(Mirror) (1)printed.left-arm.front-bearing-adapter-shoulder-mirror-1
- Left arm: bicep(Mirror) (1)printed.left-arm.bicep-mirror-1
- Left arm: power-mount-arm(Mirror) (1)printed.left-arm.power-mount-arm-mirror-1
- Left arm: yaw-cap(Mirror) (1)printed.left-arm.yaw-cap-mirror-1
- Left arm: multiplex-stack-flat(Mirror) (1)printed.left-arm.multiplex-stack-flat-mirror-1
- Left arm: top-bracket-servo-strap (1)(Mirror) (1)printed.left-arm.top-bracket-servo-strap-1-mirror-1
- Left arm: top-bracket-servo-strap(Mirror) (1)printed.left-arm.top-bracket-servo-strap-mirror-1
- Left arm: fan-mount(Mirror) (1)printed.left-arm.fan-mount-mirror-1
- Left arm: bicep-motor-mate(Mirror) (1)printed.left-arm.bicep-motor-mate-mirror-1
- Left arm: fore-arm-bicep-motor-attatch(Mirror) (1)printed.left-arm.fore-arm-bicep-motor-attatch-mirror-1
- Right arm: bicep-rotational-cuff-second-motor-bracketprinted.right-arm.bicep-rotational-cuff-second-motor-bracket
- Right arm: yaw-waist-adapter-motor-exal_MIR1printed.right-arm.yaw-waist-adapter-motor-exal-mir1
- Right arm: yaw-waist-adapter-motor-exal_MIR1 (5)printed.right-arm.yaw-waist-adapter-motor-exal-mir1-5
- Right arm: shoulder-frontprinted.right-arm.shoulder-front
- Right arm: shoulder-roll-al-mot_MIR1 (3)printed.right-arm.shoulder-roll-al-mot-mir1-3
- Right arm: shoulder-roll-al-mot_MIR1 (2)printed.right-arm.shoulder-roll-al-mot-mir1-2
- Right arm: shoulder-roll-al-mot_MIR1 (1)printed.right-arm.shoulder-roll-al-mot-mir1-1
- Right arm: shoulder-roll-al-mot_MIR1printed.right-arm.shoulder-roll-al-mot-mir1
- Right arm: shoulder-capprinted.right-arm.shoulder-cap
- Right arm: shoulder-front-bearing-adapterprinted.right-arm.shoulder-front-bearing-adapter
- Right arm: elbow-hangar1printed.right-arm.elbow-hangar1
- Right arm: elbow-hangarprinted.right-arm.elbow-hangar
- Right arm: elbow-bridge-rearprinted.right-arm.elbow-bridge-rear
- Right arm: elbow-bridge-rear (1)printed.right-arm.elbow-bridge-rear-1
- Right arm: bicep-shoulder-bracket-exal (1)printed.right-arm.bicep-shoulder-bracket-exal-1
- Right arm: bicep-shoulder-bracket-exal (2)printed.right-arm.bicep-shoulder-bracket-exal-2
- Right arm: bicep-shoulder-bracket-exal (3)printed.right-arm.bicep-shoulder-bracket-exal-3
- Right arm: bicep-shoulder-bracket-exalprinted.right-arm.bicep-shoulder-bracket-exal
- Right arm: straight-tendonprinted.right-arm.straight-tendon
- Right arm: arm-cuff-bicep-bracketprinted.right-arm.arm-cuff-bicep-bracket
- Right arm: bicep-rear-motor-adapterprinted.right-arm.bicep-rear-motor-adapter
- Right arm: shoulder-motor-bicep-rotor-bracketprinted.right-arm.shoulder-motor-bicep-rotor-bracket
- Right arm: forearm-elbow-motor-bracket-innerprinted.right-arm.forearm-elbow-motor-bracket-inner
- Right arm: forearm-elbow-motor-bracket-inner2printed.right-arm.forearm-elbow-motor-bracket-inner2
- Right arm: second-forearm-motor-strapprinted.right-arm.second-forearm-motor-strap
- Right arm: elbow-rear-hanger (1)printed.right-arm.elbow-rear-hanger-1
- Right arm: elbow-rear-hangerprinted.right-arm.elbow-rear-hanger
- Right arm: shoulder-ex-al-interface (2)printed.right-arm.shoulder-ex-al-interface-2
- Right arm: shoulder-ex-al-interface (1)printed.right-arm.shoulder-ex-al-interface-1
- Right arm: shoulder-ex-al-interfaceprinted.right-arm.shoulder-ex-al-interface
- Right arm: front-bearing-adapter-shoulderprinted.right-arm.front-bearing-adapter-shoulder
- Right arm: power-mount-armprinted.right-arm.power-mount-arm
- Right arm: bicepprinted.right-arm.bicep
- Right arm: multiplex-stack-flatprinted.right-arm.multiplex-stack-flat
- Right arm: top-bracket-servo-strap (1)printed.right-arm.top-bracket-servo-strap-1
- Right arm: top-bracket-servo-strapprinted.right-arm.top-bracket-servo-strap
- Right arm: fan-mountprinted.right-arm.fan-mount
- Right arm: bicep-motor-mateprinted.right-arm.bicep-motor-mate
- Right arm: fore-arm-bicep-motor-attatchprinted.right-arm.fore-arm-bicep-motor-attatch
- Right arm: yaw-capprinted.right-arm.yaw-cap
- Tools
- FDM printer
- Torque
- —
- Time
- —
- After
- 01
- Source
- github.com
- 08
Print both legs (9 plates each, ~204 h)
Print Left_leg_Printplates.3mf and Right_leg_Printplate.3mf (102.2 h and 101.4 h, about 2.7 kg each). These carry the walking loads: the printables README recommends CF-PETG or nylon for the leg brackets.
CHECK59 left-leg and 58 right-leg parts; thigh bushings, knee locks and ankle brackets are free of layer separation.- Parts in
- Left leg: Thigh_BUSH v3printed.left-leg.thigh-bush-v3
- Left leg: HumanoidPelvicGirdle v11_hip-roll-al-mot_MIR2 (1) v2printed.left-leg.humanoidpelvicgirdle-v11-hip-roll-al-mot-mir2-1-v2
- Left leg: left_thigh_connectorprinted.left-leg.left-thigh-connector
- Left leg: Thigh_Component3 v2printed.left-leg.thigh-component3-v2
- Left leg: Thigh_Component1 v8printed.left-leg.thigh-component1-v8
- Left leg: Thigh_left_cemmountprinted.left-leg.thigh-left-cemmount
- Left leg: basis_leftprinted.left-leg.basis-left
- Left leg: ankle-thickprinted.left-leg.ankle-thick
- Left leg: bearingstrap (1)printed.left-leg.bearingstrap-1
- Left leg: calf-motor-driver-extprinted.left-leg.calf-motor-driver-ext
- Left leg: heel-topleftprinted.left-leg.heel-topleft
- Left leg: knee-strap-second-test (1)printed.left-leg.knee-strap-second-test-1
- Left leg: heel-top_MIRleftprinted.left-leg.heel-top-mirleft
- Left leg: knee-strap-second-testprinted.left-leg.knee-strap-second-test
- Left leg: bearingstrapprinted.left-leg.bearingstrap
- Left leg: foot-imu-strapprinted.left-leg.foot-imu-strap
- Left leg: heel-bracket_leftprinted.left-leg.heel-bracket-left
- Left leg: heel-bracketleftprinted.left-leg.heel-bracketleft
- Left leg: conjstraint-knee-test-outeprinted.left-leg.conjstraint-knee-test-oute
- Left leg: conjstraint-knee-test-oute_MIRprinted.left-leg.conjstraint-knee-test-oute-mir
- Left leg: 6band (5)printed.left-leg.6band-5
- Left leg: heel-rollerprinted.left-leg.heel-roller
- Left leg: motor-calf-exal-mountprinted.left-leg.motor-calf-exal-mount
- Left leg: bearingstrap-inner-thigh(Mirror) (1)printed.left-leg.bearingstrap-inner-thigh-mirror-1
- Left leg: thigh-bracket(Mirror) (1)printed.left-leg.thigh-bracket-mirror-1
- Left leg: double-bracketprinted.left-leg.double-bracket
- Left leg: HumanoidLeftLeg v22 (1)_ankle-side-bracket123 v2printed.left-leg.humanoidleftleg-v22-1-ankle-side-bracket123-v2
- Left leg: ankle-motor-driver-bracketleftprinted.left-leg.ankle-motor-driver-bracketleft
- Left leg: ankle-motor-driver-bracket_leftprinted.left-leg.ankle-motor-driver-bracket-left
- Left leg: calf-lower-bracket_leftprinted.left-leg.calf-lower-bracket-left
- Left leg: calf-lower-bracketprinted.left-leg.calf-lower-bracket
- Left leg: ankle-side-bracketprinted.left-leg.ankle-side-bracket
- Left leg: bearing-sensor-adapterprinted.left-leg.bearing-sensor-adapter
- Left leg: double-bracket-10deg_MIR_MIR_MIR(Mirror) (1)printed.left-leg.double-bracket-10deg-mir-mir-mir-mirror-1
- Left leg: Toe v1printed.left-leg.toe-v1
- Left leg: multiplex-stackprinted.left-leg.multiplex-stack
- Left leg: calf-skin_flipprinted.left-leg.calf-skin-flip
- Left leg: bearing-sensor-adapter-armprinted.left-leg.bearing-sensor-adapter-arm
- Left leg: knee-lock-2printed.left-leg.knee-lock-2
- Left leg: calf-skinprinted.left-leg.calf-skin
- Left leg: knee-lock-2-bprinted.left-leg.knee-lock-2-b
- Left leg: new-heel-opposingprinted.left-leg.new-heel-opposing
- Left leg: tie-rod-ankle-brackket_left1printed.left-leg.tie-rod-ankle-brackket-left1
- Left leg: tie-rod-ankle-brackket_leftprinted.left-leg.tie-rod-ankle-brackket-left
- Left leg: flank(Mirror) (1)printed.left-leg.flank-mirror-1
- Left leg: flank (1)(Mirror) (1)printed.left-leg.flank-1-mirror-1
- Left leg: calf-coverprinted.left-leg.calf-cover
- Left leg: flank-front (1)(Mirror) (1)printed.left-leg.flank-front-1-mirror-1
- Left leg: flank-front(Mirror) (1)printed.left-leg.flank-front-mirror-1
- Left leg: flank-front-flipped(Mirror) (1)printed.left-leg.flank-front-flipped-mirror-1
- Right leg: CEM60_thigh_Right_Thigh_Component1 v8(Mirror) v1printed.right-leg.cem60-thigh-right-thigh-component1-v8-mirror-v1
- Right leg: CEM-right-mountprinted.right-leg.cem-right-mount
- Right leg: Thigh_BUSH v3printed.right-leg.thigh-bush-v3
- Right leg: CEM60_thigh_Left_Thigh_Component3 v2(Mirror) v1printed.right-leg.cem60-thigh-left-thigh-component3-v2-mirror-v1
- Right leg: HumanoidPelvicGirdle v11_hip-roll-al-mot_MIR2 (1) v2printed.right-leg.humanoidpelvicgirdle-v11-hip-roll-al-mot-mir2-1-v2
- Right leg: HumanoidLeftLeg_CEM60_Component216_Component2 v1printed.right-leg.humanoidleftleg-cem60-component216-component2-v1
- Right leg: basis_leftprinted.right-leg.basis-left
- Right leg: ankle-thickprinted.right-leg.ankle-thick
- Right leg: bearingstrap (1)printed.right-leg.bearingstrap-1
- Right leg: calf-motor-driver-extprinted.right-leg.calf-motor-driver-ext
- Right leg: heel-topleftprinted.right-leg.heel-topleft
- Right leg: knee-strap-second-test (1)printed.right-leg.knee-strap-second-test-1
- Right leg: heel-top_MIRleftprinted.right-leg.heel-top-mirleft
- Right leg: knee-strap-second-testprinted.right-leg.knee-strap-second-test
- Right leg: bearingstrapprinted.right-leg.bearingstrap
- Right leg: heel-bracket_leftprinted.right-leg.heel-bracket-left
- Right leg: heel-bracketleftprinted.right-leg.heel-bracketleft
- Right leg: conjstraint-knee-test-outeprinted.right-leg.conjstraint-knee-test-oute
- Right leg: conjstraint-knee-test-oute_MIRprinted.right-leg.conjstraint-knee-test-oute-mir
- Right leg: Thigh bracket v2printed.right-leg.thigh-bracket-v2
- Right leg: bearingstrap-inner-thighprinted.right-leg.bearingstrap-inner-thigh
- Right leg: 6band (5)printed.right-leg.6band-5
- Right leg: heel-rollerprinted.right-leg.heel-roller
- Right leg: motor-calf-exal-mountprinted.right-leg.motor-calf-exal-mount
- Right leg: double-bracket-10deg_MIR_MIR_MIRprinted.right-leg.double-bracket-10deg-mir-mir-mir
- Right leg: double-bracketprinted.right-leg.double-bracket
- Right leg: HumanoidLeftLeg v22 (1)_ankle-side-bracket123 v2printed.right-leg.humanoidleftleg-v22-1-ankle-side-bracket123-v2
- Right leg: ankle-motor-driver-bracketleftprinted.right-leg.ankle-motor-driver-bracketleft
- Right leg: ankle-motor-driver-bracket_leftprinted.right-leg.ankle-motor-driver-bracket-left
- Right leg: calf-lower-bracket_leftprinted.right-leg.calf-lower-bracket-left
- Right leg: calf-lower-bracketprinted.right-leg.calf-lower-bracket
- Right leg: ankle-side-bracketprinted.right-leg.ankle-side-bracket
- Right leg: bearing-sensor-adapterprinted.right-leg.bearing-sensor-adapter
- Right leg: Toe v1printed.right-leg.toe-v1
- Right leg: multiplex-stackprinted.right-leg.multiplex-stack
- Right leg: calf-skin_flipprinted.right-leg.calf-skin-flip
- Right leg: bearing-sensor-adapter-armprinted.right-leg.bearing-sensor-adapter-arm
- Right leg: knee-lock-2printed.right-leg.knee-lock-2
- Right leg: calf-skinprinted.right-leg.calf-skin
- Right leg: knee-lock-2-bprinted.right-leg.knee-lock-2-b
- Right leg: flankprinted.right-leg.flank
- Right leg: flank (1)printed.right-leg.flank-1
- Right leg: new-heel-opposingprinted.right-leg.new-heel-opposing
- Right leg: tie-rod-ankle-brackket_left1printed.right-leg.tie-rod-ankle-brackket-left1
- Right leg: tie-rod-ankle-brackket_leftprinted.right-leg.tie-rod-ankle-brackket-left
- Right leg: calf-coverprinted.right-leg.calf-cover
- Right leg: flank-frontprinted.right-leg.flank-front
- Right leg: flank-front-flippedprinted.right-leg.flank-front-flipped
- Tools
- FDM printer
- Torque
- —
- Time
- —
- After
- 01
- Source
- github.com
- 09
Print the feet (TPU soles, PLA structure)
Export the parts from foot-v3.stp. Print the yellow sole parts in 95-98A TPU and everything else in PLA at no less than 80% rectilinear infill, 5 walls and 5 top/bottom layers.
CHECKTwo feet; the TPU parts compress under thumb pressure and spring back, the PLA parts show no infill through the walls.- Parts in
- Feet: foot assembly from foot-v3.stp (TPU 95-98A for the yellow sole parts, PLA for the rest)printed.feet.foot
- Tools
- FDM printer with a TPU-capable extruder
- Torque
- —
- Time
- —
- After
- 01
- Source
- github.com
- 10
Remove supports, clean holes, test-fit
Remove supports without gouging mating faces, clear screw holes with a drill bit by hand, sand only visible surfaces. Test-fit parts to their actuator or extrusion before final assembly.
CHECKEvery bolt hole passes its screw by hand and every extrusion slot face sits flat on a 20x20 profile.- Parts in
- —
- Tools
- Flush cutters, Drill bits matching M3/M4/M5/M8 clearance, 220-400 grit sandpaper
- Torque
- —
- Time
- 4 h
- Source
- github.com
- Feet11
Feet: load cells and HX711 readers
Convert each HX711 from 10 Hz to 80 Hz (lift pin 15 and tie it to pin 16). Wire four HX711s per foot to an ESP32 DevKit v1: all VCC to 3V3, shared SCK on GPIO 4, DOUT on GPIO 32, 12, 13 and 15. Flash pressure.ino and map pads with interface.py.
CHECKEach load cell reads about 1 kΩ between signal and each excitation wire and 2 kΩ across excitation; pressing each pad changes only its own channel.- Parts in
- Feet: foot assembly from foot-v3.stp (TPU 95-98A for the yellow sole parts, PLA for the rest)printed.feet.foot
- Half-bridge load cell, 50 kg (4 per foot)sensor.load-cell
- HX711 load-cell amplifier, one per load cell (modified for 80 Hz)electronics.hx711
- ESP32 DevKit v1: foot pressure reader (one per foot)electronics.esp32-feet
- Tools
- Soldering iron, Digital multimeter
- Torque
- —
- Time
- 7 h
- After
- 09
- Source
- github.com
- Head12
Six-leg stepper neck (Stewart platform)
Couple each NEMA 17 to its 100 mm lead screw with a universal joint, run the brass nut up each screw, and join the six legs to the head plate through the second set of universal joints. Wire each A4988 STEP/DIR to the ESP32 per the neck pin map (motor 1: 33/32 through motor 6: 21/13), tie EN low, and set each driver's current limit before powering the motors (12-24 V).
CHECKTurning each lead screw by hand moves the head smoothly end to end; with power on, `X0,Y0,Z0,H0` returns the head level.- Parts in
- NEMA 17 stepper, 1.8°, 42x40 mm, 0.4 Nm: Stewart-platform neckactuator.nema17
- A4988 stepper driver (8-35 V, 2 A): neckelectronics.stepper-driver
- A4988 driver shield / breakout board, 24-48 V: neckelectronics.stepper-shield
- M8 (T8, 2 mm pitch) lead screw, 100 mm: neck legsstructure.leadscrew-t8
- T8 4-start lead-screw nut, brass, anti-backlash: neckstructure.t8-nut
- Universal joint 5x8 mm, stainless: stepper to lead screwstructure.ujoint-5x8
- Universal joint 8x8 mm, stainless: neck to headstructure.ujoint-8x8
- Socket head cap screw M3 x 10 mm (head 24)fastener.shcs-m3x10
- Countersunk hex socket screw M3 x 10 mm (head 24)fastener.csk-m3x10
- Socket head cap screw M6 x 65 mm (head 6)fastener.shcs-m6x65
- Head: base-stepper-mountprinted.head.base-stepper-mount
- Head: center-bracket2printed.head.center-bracket2
- Head: realsense 2printed.head.realsense-2
- Head: Screw_cylinder v3printed.head.screw-cylinder-v3
- Head: neck-driver-mountprinted.head.neck-driver-mount
- Head: neck-stack-secondaryprinted.head.neck-stack-secondary
- Head: inner-antenna-holderprinted.head.inner-antenna-holder
- Head: Head v12_new-neck v2printed.head.head-v12-new-neck-v2
- Head: spidar_10mm v7printed.head.spidar-10mm-v7
- Head: spidar_8mm v6printed.head.spidar-8mm-v6
- Head: rear-baseprinted.head.rear-base
- Head: front-plateprinted.head.front-plate
- Head: neck-backprinted.head.neck-back
- Head: mouth2printed.head.mouth2
- Head: center-bracketprinted.head.center-bracket
- Head: temple2printed.head.temple2
- Head: realsense-bracketprinted.head.realsense-bracket
- Head: GPIO_Rail_AGXprinted.head.gpio-rail-agx
- Head: base-coverprinted.head.base-cover
- Tools
- Allen keys M3, M4, M6, Small screwdriver for driver current trim, Digital multimeter
- Torque
- —
- Time
- 2 h 30 min
- After
- 04
- Source
- github.com
- Left leg13
Left leg: hip and thigh
Mount the hip actuators in the order yaw, roll, pitch with thread locker on every mounting bolt, and seat the bearings that carry axial load. Install the hip pitch CEM-60 (ID 40), then the knee CEM-60 (ID 43) in the thigh. Route actuator cables through the internal channels before closing the thigh.
CHECKHip pitch swings ±30° by hand, unpowered, with no binding and no cable snag.- Parts in
- MyActuator CEM-60 (48 V, CAN, 20 Nm): 2 pelvis + 4 legs (hip and knee pitch)actuator.cem-60
- MyActuator RMD-X8 (24-48 V, CAN, 24 Nm): legsactuator.rmd-x8
- Ball bearing 608ZZ, 8x22x7 mm (pelvis 12, legs 36)structure.bearing-608zz
- Socket head cap screw M8 x 45 mm (legs 6)fastener.shcs-m8x45
- Socket head cap screw M8 x 60 mm (legs 6)fastener.shcs-m8x60
- Socket head cap screw M4 x 35 mm (arms 14, pelvic 2, legs 30)fastener.shcs-m4x35
- Left leg: Thigh_BUSH v3printed.left-leg.thigh-bush-v3
- Left leg: HumanoidPelvicGirdle v11_hip-roll-al-mot_MIR2 (1) v2printed.left-leg.humanoidpelvicgirdle-v11-hip-roll-al-mot-mir2-1-v2
- Left leg: left_thigh_connectorprinted.left-leg.left-thigh-connector
- Left leg: Thigh_Component3 v2printed.left-leg.thigh-component3-v2
- Left leg: Thigh_Component1 v8printed.left-leg.thigh-component1-v8
- Left leg: Thigh_left_cemmountprinted.left-leg.thigh-left-cemmount
- Left leg: basis_leftprinted.left-leg.basis-left
- Left leg: ankle-thickprinted.left-leg.ankle-thick
- Left leg: bearingstrap (1)printed.left-leg.bearingstrap-1
- Left leg: calf-motor-driver-extprinted.left-leg.calf-motor-driver-ext
- Left leg: heel-topleftprinted.left-leg.heel-topleft
- Left leg: knee-strap-second-test (1)printed.left-leg.knee-strap-second-test-1
- Left leg: heel-top_MIRleftprinted.left-leg.heel-top-mirleft
- Left leg: knee-strap-second-testprinted.left-leg.knee-strap-second-test
- Left leg: bearingstrapprinted.left-leg.bearingstrap
- Left leg: foot-imu-strapprinted.left-leg.foot-imu-strap
- Left leg: heel-bracket_leftprinted.left-leg.heel-bracket-left
- Left leg: heel-bracketleftprinted.left-leg.heel-bracketleft
- Left leg: conjstraint-knee-test-outeprinted.left-leg.conjstraint-knee-test-oute
- Left leg: conjstraint-knee-test-oute_MIRprinted.left-leg.conjstraint-knee-test-oute-mir
- Left leg: 6band (5)printed.left-leg.6band-5
- Left leg: heel-rollerprinted.left-leg.heel-roller
- Left leg: motor-calf-exal-mountprinted.left-leg.motor-calf-exal-mount
- Left leg: bearingstrap-inner-thigh(Mirror) (1)printed.left-leg.bearingstrap-inner-thigh-mirror-1
- Left leg: thigh-bracket(Mirror) (1)printed.left-leg.thigh-bracket-mirror-1
- Left leg: double-bracketprinted.left-leg.double-bracket
- Left leg: HumanoidLeftLeg v22 (1)_ankle-side-bracket123 v2printed.left-leg.humanoidleftleg-v22-1-ankle-side-bracket123-v2
- Left leg: ankle-motor-driver-bracketleftprinted.left-leg.ankle-motor-driver-bracketleft
- Left leg: ankle-motor-driver-bracket_leftprinted.left-leg.ankle-motor-driver-bracket-left
- Left leg: calf-lower-bracket_leftprinted.left-leg.calf-lower-bracket-left
- Left leg: calf-lower-bracketprinted.left-leg.calf-lower-bracket
- Left leg: ankle-side-bracketprinted.left-leg.ankle-side-bracket
- Left leg: bearing-sensor-adapterprinted.left-leg.bearing-sensor-adapter
- Left leg: double-bracket-10deg_MIR_MIR_MIR(Mirror) (1)printed.left-leg.double-bracket-10deg-mir-mir-mir-mirror-1
- Left leg: Toe v1printed.left-leg.toe-v1
- Left leg: multiplex-stackprinted.left-leg.multiplex-stack
- Left leg: calf-skin_flipprinted.left-leg.calf-skin-flip
- Left leg: bearing-sensor-adapter-armprinted.left-leg.bearing-sensor-adapter-arm
- Left leg: knee-lock-2printed.left-leg.knee-lock-2
- Left leg: calf-skinprinted.left-leg.calf-skin
- Left leg: knee-lock-2-bprinted.left-leg.knee-lock-2-b
- Left leg: new-heel-opposingprinted.left-leg.new-heel-opposing
- Left leg: tie-rod-ankle-brackket_left1printed.left-leg.tie-rod-ankle-brackket-left1
- Left leg: tie-rod-ankle-brackket_leftprinted.left-leg.tie-rod-ankle-brackket-left
- Left leg: flank(Mirror) (1)printed.left-leg.flank-mirror-1
- Left leg: flank (1)(Mirror) (1)printed.left-leg.flank-1-mirror-1
- Left leg: calf-coverprinted.left-leg.calf-cover
- Left leg: flank-front (1)(Mirror) (1)printed.left-leg.flank-front-1-mirror-1
- Left leg: flank-front(Mirror) (1)printed.left-leg.flank-front-mirror-1
- Left leg: flank-front-flipped(Mirror) (1)printed.left-leg.flank-front-flipped-mirror-1
- Tools
- Allen keys M4, M8, Medium-strength thread locker
- Torque
- —
- Time
- 4 h
- Source
- github.com
- Right leg14
Right leg: repeat hip, knee, shin and ankle
Build the right leg the same way with the right-leg plates: hip pitch CEM-60 at ID 50, knee at ID 53. Check each part name before fitting; the right-leg plate reuses some parts named for the left.
CHECKHeld side by side with the left leg, joint axes line up and both knees stop at the same angle.- Parts in
- MyActuator CEM-60 (48 V, CAN, 20 Nm): 2 pelvis + 4 legs (hip and knee pitch)actuator.cem-60
- MyActuator RMD-X8 (24-48 V, CAN, 24 Nm): legsactuator.rmd-x8
- Tie rod 8 mm x 210 mm, steel, M8 ends: ankle drivestructure.tie-rod-210
- Tie rod 8 mm x 290 mm, steel, M8 ends: ankle drivestructure.tie-rod-290
- Rod end bearing, female M8x1.25 (FK8)structure.rod-end-m8
- Ball bearing 608ZZ, 8x22x7 mm (pelvis 12, legs 36)structure.bearing-608zz
- Right leg: CEM60_thigh_Right_Thigh_Component1 v8(Mirror) v1printed.right-leg.cem60-thigh-right-thigh-component1-v8-mirror-v1
- Right leg: CEM-right-mountprinted.right-leg.cem-right-mount
- Right leg: Thigh_BUSH v3printed.right-leg.thigh-bush-v3
- Right leg: CEM60_thigh_Left_Thigh_Component3 v2(Mirror) v1printed.right-leg.cem60-thigh-left-thigh-component3-v2-mirror-v1
- Right leg: HumanoidPelvicGirdle v11_hip-roll-al-mot_MIR2 (1) v2printed.right-leg.humanoidpelvicgirdle-v11-hip-roll-al-mot-mir2-1-v2
- Right leg: HumanoidLeftLeg_CEM60_Component216_Component2 v1printed.right-leg.humanoidleftleg-cem60-component216-component2-v1
- Right leg: basis_leftprinted.right-leg.basis-left
- Right leg: ankle-thickprinted.right-leg.ankle-thick
- Right leg: bearingstrap (1)printed.right-leg.bearingstrap-1
- Right leg: calf-motor-driver-extprinted.right-leg.calf-motor-driver-ext
- Right leg: heel-topleftprinted.right-leg.heel-topleft
- Right leg: knee-strap-second-test (1)printed.right-leg.knee-strap-second-test-1
- Right leg: heel-top_MIRleftprinted.right-leg.heel-top-mirleft
- Right leg: knee-strap-second-testprinted.right-leg.knee-strap-second-test
- Right leg: bearingstrapprinted.right-leg.bearingstrap
- Right leg: heel-bracket_leftprinted.right-leg.heel-bracket-left
- Right leg: heel-bracketleftprinted.right-leg.heel-bracketleft
- Right leg: conjstraint-knee-test-outeprinted.right-leg.conjstraint-knee-test-oute
- Right leg: conjstraint-knee-test-oute_MIRprinted.right-leg.conjstraint-knee-test-oute-mir
- Right leg: Thigh bracket v2printed.right-leg.thigh-bracket-v2
- Right leg: bearingstrap-inner-thighprinted.right-leg.bearingstrap-inner-thigh
- Right leg: 6band (5)printed.right-leg.6band-5
- Right leg: heel-rollerprinted.right-leg.heel-roller
- Right leg: motor-calf-exal-mountprinted.right-leg.motor-calf-exal-mount
- Right leg: double-bracket-10deg_MIR_MIR_MIRprinted.right-leg.double-bracket-10deg-mir-mir-mir
- Right leg: double-bracketprinted.right-leg.double-bracket
- Right leg: HumanoidLeftLeg v22 (1)_ankle-side-bracket123 v2printed.right-leg.humanoidleftleg-v22-1-ankle-side-bracket123-v2
- Right leg: ankle-motor-driver-bracketleftprinted.right-leg.ankle-motor-driver-bracketleft
- Right leg: ankle-motor-driver-bracket_leftprinted.right-leg.ankle-motor-driver-bracket-left
- Right leg: calf-lower-bracket_leftprinted.right-leg.calf-lower-bracket-left
- Right leg: calf-lower-bracketprinted.right-leg.calf-lower-bracket
- Right leg: ankle-side-bracketprinted.right-leg.ankle-side-bracket
- Right leg: bearing-sensor-adapterprinted.right-leg.bearing-sensor-adapter
- Right leg: Toe v1printed.right-leg.toe-v1
- Right leg: multiplex-stackprinted.right-leg.multiplex-stack
- Right leg: calf-skin_flipprinted.right-leg.calf-skin-flip
- Right leg: bearing-sensor-adapter-armprinted.right-leg.bearing-sensor-adapter-arm
- Right leg: knee-lock-2printed.right-leg.knee-lock-2
- Right leg: calf-skinprinted.right-leg.calf-skin
- Right leg: knee-lock-2-bprinted.right-leg.knee-lock-2-b
- Right leg: flankprinted.right-leg.flank
- Right leg: flank (1)printed.right-leg.flank-1
- Right leg: new-heel-opposingprinted.right-leg.new-heel-opposing
- Right leg: tie-rod-ankle-brackket_left1printed.right-leg.tie-rod-ankle-brackket-left1
- Right leg: tie-rod-ankle-brackket_leftprinted.right-leg.tie-rod-ankle-brackket-left
- Right leg: calf-coverprinted.right-leg.calf-cover
- Right leg: flank-frontprinted.right-leg.flank-front
- Right leg: flank-front-flippedprinted.right-leg.flank-front-flipped
- Tools
- Allen keys M4, M5, M8, Medium-strength thread locker
- Torque
- —
- Time
- 7 h
- Source
- github.com
- Pelvis15
Pelvis frame and bearing seats
Inspect and clean the pelvis prints, press the 12 bearings into the hip rotation seats, and build the frame on two 150 mm, one 200 mm and one 85 mm extrusion with the profile locks.
CHECKThe frame sits flat on a table without rocking and every bearing spins freely.- Parts in
- 20x20 slot-6 aluminium extrusion, 150 mm (torso 8, arms 2, pelvic 2, legs 4)structure.extrusion-2020-150
- 20x20 slot-6 aluminium extrusion, 200 mm (torso 10, pelvic 1)structure.extrusion-2020-200
- 20x20 slot-6 aluminium extrusion, 85 mm (pelvic 1)structure.extrusion-2020-85
- Ball bearing 608ZZ, 8x22x7 mm (pelvis 12, legs 36)structure.bearing-608zz
- Socket head cap screw M4 x 70 mm (pelvic 12)fastener.shcs-m4x70
- Socket head cap screw M8 x 170 mm (pelvic 1)fastener.shcs-m8x170
- Hex lock nut (nylon insert) M8 (pelvic 5)fastener.locknut-m8
- Pelvis: Hip_CEMmount_front_Topprinted.pelvic-girdle.hip-cemmount-front-top
- Pelvis: lumbareprinted.pelvic-girdle.lumbare
- Pelvis: Hip_CEMmount_front_downprinted.pelvic-girdle.hip-cemmount-front-down
- Pelvis: HumanoidPelvicGirdle v11_naval (1) v2printed.pelvic-girdle.humanoidpelvicgirdle-v11-naval-1-v2
- Pelvis: Component2printed.pelvic-girdle.component2
- Pelvis: Component2(Mirror)printed.pelvic-girdle.component2-mirror
- Pelvis: Lumbar Mountsprinted.pelvic-girdle.lumbar-mounts
- Pelvis: Hip_rmd_spacer2printed.pelvic-girdle.hip-rmd-spacer2
- Pelvis: Hip_rmd_spacer1printed.pelvic-girdle.hip-rmd-spacer1
- Pelvis: Hip_profilelock2printed.pelvic-girdle.hip-profilelock2
- Pelvis: Hip_profilelock1printed.pelvic-girdle.hip-profilelock1
- Pelvis: Hip_rmdmount2printed.pelvic-girdle.hip-rmdmount2
- Pelvis: Hip_rmd_mount4printed.pelvic-girdle.hip-rmd-mount4
- Pelvis: Hip_rmdmount3printed.pelvic-girdle.hip-rmdmount3
- Pelvis: Hip_rmdmount1printed.pelvic-girdle.hip-rmdmount1
- Pelvis: Groin_frontprinted.pelvic-girdle.groin-front
- Pelvis: butt_centr1printed.pelvic-girdle.butt-centr1
- Pelvis: Bearing_holder2printed.pelvic-girdle.bearing-holder2
- Pelvis: HumanoidPelvicGirdle v11_hips-front-mount v2printed.pelvic-girdle.humanoidpelvicgirdle-v11-hips-front-mount-v2
- Pelvis: Groin centreprinted.pelvic-girdle.groin-centre
- Pelvis: HumanoidPelvicGirdle v11_front-bearing-strap (1) v2printed.pelvic-girdle.humanoidpelvicgirdle-v11-front-bearing-strap-1-v2
- Pelvis: Butt_centre2printed.pelvic-girdle.butt-centre2
- Pelvis: Backprinted.pelvic-girdle.back
- Pelvis: Bearing Holder1printed.pelvic-girdle.bearing-holder1
- Pelvis: Hip_roll_R2printed.pelvic-girdle.hip-roll-r2
- Pelvis: Hip_roll_R1printed.pelvic-girdle.hip-roll-r1
- Pelvis: Hip_roll_L2printed.pelvic-girdle.hip-roll-l2
- Pelvis: Hip_roll_l1printed.pelvic-girdle.hip-roll-l1
- Tools
- Allen keys M4, M8, Rubber mallet
- Torque
- —
- Time
- 1 h
- Source
- github.com
- Torso16
Torso frame
Build the torso cage from 6x100, 8x150, 10x200, 1x300 and 1x350 mm extrusion with the printed ribs and spline supports: 86 countersunk M4x16 and 45 M4x16 cap screws into the pre-loaded T-nuts.
CHECKDiagonals across the cage match within 2 mm and the cage does not rack under hand pressure.- Parts in
- 20x20 slot-6 aluminium extrusion, 100 mm (torso 6, arms 4, legs 2)structure.extrusion-2020-100
- 20x20 slot-6 aluminium extrusion, 150 mm (torso 8, arms 2, pelvic 2, legs 4)structure.extrusion-2020-150
- 20x20 slot-6 aluminium extrusion, 200 mm (torso 10, pelvic 1)structure.extrusion-2020-200
- 20x20 slot-6 aluminium extrusion, 300 mm (torso 1, legs 2)structure.extrusion-2020-300
- 20x20 slot-6 aluminium extrusion, 350 mm (torso 1)structure.extrusion-2020-350
- Countersunk hex socket screw M4 x 16 mm (torso 86, legs 16)fastener.csk-m4x16
- Socket head cap screw M4 x 16 mm (torso 45, arms 30, head 2, pelvic 26, legs 54)fastener.shcs-m4x16
- Extrusion T-nut M4, slot 6 (torso 155, arms 64, pelvic 28)fastener.tnut-m4-slot6
- Torso: neck-chest-interface2printed.torso.neck-chest-interface2
- Torso: Front_mid_left_rib v2printed.torso.front-mid-left-rib-v2
- Torso: Front_mid_right_rib v2printed.torso.front-mid-right-rib-v2
- Torso: back_left_splinesupport v3printed.torso.back-left-splinesupport-v3
- Torso: back_right_splinesupport v4printed.torso.back-right-splinesupport-v4
- Torso: handle (1)printed.torso.handle-1
- Torso: handleprinted.torso.handle
- Torso: left_rmd_x10mount v2printed.torso.left-rmd-x10mount-v2
- Torso: right_rmdx10mount v2printed.torso.right-rmdx10mount-v2
- Torso: HumanoidTorso_left-front-rib-lower v4printed.torso.humanoidtorso-left-front-rib-lower-v4
- Torso: HumanoidTorso_Right-front-rib-lower_Component2 v1printed.torso.humanoidtorso-right-front-rib-lower-component2-v1
- Torso: Torso_ug_front-Left-shoulder_Component2 v1printed.torso.torso-ug-front-left-shoulder-component2-v1
- Torso: Torso_ug_front-right-shoulder v5printed.torso.torso-ug-front-right-shoulder-v5
- Torso: Left_back_shoulder v5printed.torso.left-back-shoulder-v5
- Torso: Right_back_shoulder v11printed.torso.right-back-shoulder-v11
- Torso: killswitch-spine-interfaceprinted.torso.killswitch-spine-interface
- Torso: button-holderprinted.torso.button-holder
- Torso: back_lower_rightrib v2printed.torso.back-lower-rightrib-v2
- Torso: back_lower_leftrib v2printed.torso.back-lower-leftrib-v2
- Torso: right_battery_mount v3printed.torso.right-battery-mount-v3
- Torso: left_battery_mount v2printed.torso.left-battery-mount-v2
- Torso: battery-monitor-holderprinted.torso.battery-monitor-holder
- Torso: 6band (1) v1printed.torso.6band-1-v1
- Torso: Back_middle_Strap v5printed.torso.back-middle-strap-v5
- Torso: Front_middle_Strap v4printed.torso.front-middle-strap-v4
- Torso: rear-right-shoulder_MIRprinted.torso.rear-right-shoulder-mir
- Torso: rear-right-shoulderprinted.torso.rear-right-shoulder
- Torso: HumanoidTorso_lumbar-strap v1printed.torso.humanoidtorso-lumbar-strap-v1
- Torso: HumanoidTorso_naval-strap (1) v1printed.torso.humanoidtorso-naval-strap-1-v1
- Torso: head-power-supply-bracketprinted.torso.head-power-supply-bracket
- Tools
- Allen keys M4, Square
- Torque
- —
- Time
- 2 h 30 min
- Source
- github.com
- Arms17
Left arm
Install the shoulder actuators first (most constrained), then bicep, elbow and wrist around the actuators, routing cables through the internal cover channels. IDs 31-35: wrist, elbow, rotate, shoulder out, shoulder rotate.
CHECKEach joint reaches its documented range by hand without the harness pulling tight: wrist 0-50°, elbow -40-31°, rotate ±140°, shoulder out -90-0°, shoulder rotate 0-90°.- Parts in
- MyActuator RMD-X6 (24 V, CAN, 8 Nm): armsactuator.rmd-x6
- 20x20 slot-6 aluminium extrusion, 100 mm (torso 6, arms 4, legs 2)structure.extrusion-2020-100
- 20x20 slot-6 aluminium extrusion, 150 mm (torso 8, arms 2, pelvic 2, legs 4)structure.extrusion-2020-150
- Socket head cap screw M5 x 35 mm (arms 8)fastener.shcs-m5x35
- Socket head cap screw M5 x 40 mm (arms 8)fastener.shcs-m5x40
- Socket head cap screw M5 x 55 mm (arms 8)fastener.shcs-m5x55
- Socket head cap screw M6 x 50 mm (arms 8)fastener.shcs-m6x50
- Plain hex nut M5 (arms 24)fastener.hexnut-m5
- Hex lock nut (nylon insert) M6 (arms 12)fastener.locknut-m6
- Left arm: bicep-rotational-cuff-second-motor-bracket(Mirror) (1)printed.left-arm.bicep-rotational-cuff-second-motor-bracket-mirror-1
- Left arm: yaw-waist-adapter-motor-exal_MIR1 (5)(Mirror) (1)printed.left-arm.yaw-waist-adapter-motor-exal-mir1-5-mirror-1
- Left arm: yaw-waist-adapter-motor-exal_MIR1(Mirror) (1)printed.left-arm.yaw-waist-adapter-motor-exal-mir1-mirror-1
- Left arm: shoulder-front(Mirror) (1)printed.left-arm.shoulder-front-mirror-1
- Left arm: shoulder-cap(Mirror) (1)printed.left-arm.shoulder-cap-mirror-1
- Left arm: shoulder-front-bearing-adapter(Mirror) (1)printed.left-arm.shoulder-front-bearing-adapter-mirror-1
- Left arm: elbow-hangar(Mirror) (1)printed.left-arm.elbow-hangar-mirror-1
- Left arm: elbow-hangar1(Mirror) (1)printed.left-arm.elbow-hangar1-mirror-1
- Left arm: elbow-bridge-rear (1)(Mirror) (1)printed.left-arm.elbow-bridge-rear-1-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1 (1)(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-1-mirror-1
- Left arm: elbow-bridge-rear(Mirror) (1)printed.left-arm.elbow-bridge-rear-mirror-1
- Left arm: bicep-shoulder-bracket-exal (1)(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-1-mirror-1
- Left arm: bicep-shoulder-bracket-exal (2)(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-2-mirror-1
- Left arm: bicep-shoulder-bracket-exal (3)(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-3-mirror-1
- Left arm: bicep-shoulder-bracket-exal(Mirror) (1)printed.left-arm.bicep-shoulder-bracket-exal-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1 (2)(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-2-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1 (3)(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-3-mirror-1
- Left arm: shoulder-roll-al-mot_MIR1(Mirror) (1)printed.left-arm.shoulder-roll-al-mot-mir1-mirror-1
- Left arm: straight-tendon(Mirror) (1)printed.left-arm.straight-tendon-mirror-1
- Left arm: arm-cuff-bicep-bracket(Mirror) (1)printed.left-arm.arm-cuff-bicep-bracket-mirror-1
- Left arm: bicep-rear-motor-adapter(Mirror) (1)printed.left-arm.bicep-rear-motor-adapter-mirror-1
- Left arm: shoulder-motor-bicep-rotor-bracket(Mirror) (1)printed.left-arm.shoulder-motor-bicep-rotor-bracket-mirror-1
- Left arm: forearm-elbow-motor-bracket-inner(Mirror) (1)printed.left-arm.forearm-elbow-motor-bracket-inner-mirror-1
- Left arm: forearm-elbow-motor-bracket-inner2(Mirror) (1)printed.left-arm.forearm-elbow-motor-bracket-inner2-mirror-1
- Left arm: second-forearm-motor-strap(Mirror) (1)printed.left-arm.second-forearm-motor-strap-mirror-1
- Left arm: shoulder-ex-al-interface(Mirror) (1)printed.left-arm.shoulder-ex-al-interface-mirror-1
- Left arm: elbow-rear-hanger(Mirror) (1)printed.left-arm.elbow-rear-hanger-mirror-1
- Left arm: shoulder-ex-al-interface (1)(Mirror) (1)printed.left-arm.shoulder-ex-al-interface-1-mirror-1
- Left arm: shoulder-ex-al-interface (2)(Mirror) (1)printed.left-arm.shoulder-ex-al-interface-2-mirror-1
- Left arm: elbow-rear-hanger (1)(Mirror) (1)printed.left-arm.elbow-rear-hanger-1-mirror-1
- Left arm: front-bearing-adapter-shoulder(Mirror) (1)printed.left-arm.front-bearing-adapter-shoulder-mirror-1
- Left arm: bicep(Mirror) (1)printed.left-arm.bicep-mirror-1
- Left arm: power-mount-arm(Mirror) (1)printed.left-arm.power-mount-arm-mirror-1
- Left arm: yaw-cap(Mirror) (1)printed.left-arm.yaw-cap-mirror-1
- Left arm: multiplex-stack-flat(Mirror) (1)printed.left-arm.multiplex-stack-flat-mirror-1
- Left arm: top-bracket-servo-strap (1)(Mirror) (1)printed.left-arm.top-bracket-servo-strap-1-mirror-1
- Left arm: top-bracket-servo-strap(Mirror) (1)printed.left-arm.top-bracket-servo-strap-mirror-1
- Left arm: fan-mount(Mirror) (1)printed.left-arm.fan-mount-mirror-1
- Left arm: bicep-motor-mate(Mirror) (1)printed.left-arm.bicep-motor-mate-mirror-1
- Left arm: fore-arm-bicep-motor-attatch(Mirror) (1)printed.left-arm.fore-arm-bicep-motor-attatch-mirror-1
- Tools
- Allen keys M4, M5, M6
- Torque
- —
- Time
- 6 h
- Source
- github.com
- 18
Right arm
Build the right arm the same way. IDs 21-25: wrist roll, elbow pitch, rotate, shoulder out, shoulder rotate.
CHECKRanges by hand: wrist 0-50°, elbow ±31°, rotate 5-40°, shoulder out -31-90°, shoulder rotate 15-45°.- Parts in
- MyActuator RMD-X6 (24 V, CAN, 8 Nm): armsactuator.rmd-x6
- Right arm: bicep-rotational-cuff-second-motor-bracketprinted.right-arm.bicep-rotational-cuff-second-motor-bracket
- Right arm: yaw-waist-adapter-motor-exal_MIR1printed.right-arm.yaw-waist-adapter-motor-exal-mir1
- Right arm: yaw-waist-adapter-motor-exal_MIR1 (5)printed.right-arm.yaw-waist-adapter-motor-exal-mir1-5
- Right arm: shoulder-frontprinted.right-arm.shoulder-front
- Right arm: shoulder-roll-al-mot_MIR1 (3)printed.right-arm.shoulder-roll-al-mot-mir1-3
- Right arm: shoulder-roll-al-mot_MIR1 (2)printed.right-arm.shoulder-roll-al-mot-mir1-2
- Right arm: shoulder-roll-al-mot_MIR1 (1)printed.right-arm.shoulder-roll-al-mot-mir1-1
- Right arm: shoulder-roll-al-mot_MIR1printed.right-arm.shoulder-roll-al-mot-mir1
- Right arm: shoulder-capprinted.right-arm.shoulder-cap
- Right arm: shoulder-front-bearing-adapterprinted.right-arm.shoulder-front-bearing-adapter
- Right arm: elbow-hangar1printed.right-arm.elbow-hangar1
- Right arm: elbow-hangarprinted.right-arm.elbow-hangar
- Right arm: elbow-bridge-rearprinted.right-arm.elbow-bridge-rear
- Right arm: elbow-bridge-rear (1)printed.right-arm.elbow-bridge-rear-1
- Right arm: bicep-shoulder-bracket-exal (1)printed.right-arm.bicep-shoulder-bracket-exal-1
- Right arm: bicep-shoulder-bracket-exal (2)printed.right-arm.bicep-shoulder-bracket-exal-2
- Right arm: bicep-shoulder-bracket-exal (3)printed.right-arm.bicep-shoulder-bracket-exal-3
- Right arm: bicep-shoulder-bracket-exalprinted.right-arm.bicep-shoulder-bracket-exal
- Right arm: straight-tendonprinted.right-arm.straight-tendon
- Right arm: arm-cuff-bicep-bracketprinted.right-arm.arm-cuff-bicep-bracket
- Right arm: bicep-rear-motor-adapterprinted.right-arm.bicep-rear-motor-adapter
- Right arm: shoulder-motor-bicep-rotor-bracketprinted.right-arm.shoulder-motor-bicep-rotor-bracket
- Right arm: forearm-elbow-motor-bracket-innerprinted.right-arm.forearm-elbow-motor-bracket-inner
- Right arm: forearm-elbow-motor-bracket-inner2printed.right-arm.forearm-elbow-motor-bracket-inner2
- Right arm: second-forearm-motor-strapprinted.right-arm.second-forearm-motor-strap
- Right arm: elbow-rear-hanger (1)printed.right-arm.elbow-rear-hanger-1
- Right arm: elbow-rear-hangerprinted.right-arm.elbow-rear-hanger
- Right arm: shoulder-ex-al-interface (2)printed.right-arm.shoulder-ex-al-interface-2
- Right arm: shoulder-ex-al-interface (1)printed.right-arm.shoulder-ex-al-interface-1
- Right arm: shoulder-ex-al-interfaceprinted.right-arm.shoulder-ex-al-interface
- Right arm: front-bearing-adapter-shoulderprinted.right-arm.front-bearing-adapter-shoulder
- Right arm: power-mount-armprinted.right-arm.power-mount-arm
- Right arm: bicepprinted.right-arm.bicep
- Right arm: multiplex-stack-flatprinted.right-arm.multiplex-stack-flat
- Right arm: top-bracket-servo-strap (1)printed.right-arm.top-bracket-servo-strap-1
- Right arm: top-bracket-servo-strapprinted.right-arm.top-bracket-servo-strap
- Right arm: fan-mountprinted.right-arm.fan-mount
- Right arm: bicep-motor-mateprinted.right-arm.bicep-motor-mate
- Right arm: fore-arm-bicep-motor-attatchprinted.right-arm.fore-arm-bicep-motor-attatch
- Right arm: yaw-capprinted.right-arm.yaw-cap
- Tools
- Allen keys M4, M5, M6
- Torque
- —
- Time
- 6 h
- Source
- github.com
- Head19
Head shell, camera, router and antennas
Mount the RealSense D455f rigidly in its bracket, then the LTE router, antennas and fan. Handle the camera by its housing only.
CHECKThe camera does not move when the head is tapped, and the router's Wi-Fi is visible from a phone.- Parts in
- Intel RealSense D455f depth camera (1280x800, 90 fps, IP52)sensor.depth-camera
- 4G LTE Wi-Fi router (WE826-Q), headelectronics.lte-router
- 2.4 GHz FPV antenna, RP-SMA male, 2 dBi (2 with cable, or 4 without; match router ports)electronics.antenna
- Easycargo 30 mm fan, 5 V / 3.3 V DCelectronics.fan-30mm
- Socket head cap screw M4 x 30 mm (arms 4, head 15, legs 2)fastener.shcs-m4x30
- Hex lock nut (nylon insert) M4 (arms 36, head 47, pelvic 15)fastener.locknut-m4
- Tools
- ESD strap
- Torque
- —
- Time
- 1 h
- After
- 12
- Source
- github.com
- Firmware20
Flash the neck and foot controllers
Flash the neck ESP32 from Dropbear-Neck-Assembly (PlatformIO, FastAccelStepper) and each foot ESP32 with pressure.ino.
CHECKThe neck answers direct commands (`1:10`) over USB serial or the NECK_BT Bluetooth link, and each foot streams four channels.- Parts in
- ESP32 DevKit v1: foot pressure reader (one per foot)electronics.esp32-feet
- Tools
- PlatformIO, Arduino IDE
- Torque
- —
- Time
- 45 min
- Source
- github.com
- Left leg21
Left leg: knee and shin
Join thigh to shin through the knee actuator, fit the knee locks and the calf motor mounts, and complete the shin with its ankle mounting brackets.
CHECKThe knee bends 0-120° by hand and the mechanical stop prevents hyperextension.- Parts in
- Socket head cap screw M4 x 80 mm (torso 2, legs 10)fastener.shcs-m4x80
- Socket head cap screw M5 x 45 mm (arms 8, legs 8)fastener.shcs-m5x45
- Socket head cap screw M5 x 50 mm (legs 8)fastener.shcs-m5x50
- Left leg: Thigh_BUSH v3printed.left-leg.thigh-bush-v3
- Left leg: HumanoidPelvicGirdle v11_hip-roll-al-mot_MIR2 (1) v2printed.left-leg.humanoidpelvicgirdle-v11-hip-roll-al-mot-mir2-1-v2
- Left leg: left_thigh_connectorprinted.left-leg.left-thigh-connector
- Left leg: Thigh_Component3 v2printed.left-leg.thigh-component3-v2
- Left leg: Thigh_Component1 v8printed.left-leg.thigh-component1-v8
- Left leg: Thigh_left_cemmountprinted.left-leg.thigh-left-cemmount
- Left leg: basis_leftprinted.left-leg.basis-left
- Left leg: ankle-thickprinted.left-leg.ankle-thick
- Left leg: bearingstrap (1)printed.left-leg.bearingstrap-1
- Left leg: calf-motor-driver-extprinted.left-leg.calf-motor-driver-ext
- Left leg: heel-topleftprinted.left-leg.heel-topleft
- Left leg: knee-strap-second-test (1)printed.left-leg.knee-strap-second-test-1
- Left leg: heel-top_MIRleftprinted.left-leg.heel-top-mirleft
- Left leg: knee-strap-second-testprinted.left-leg.knee-strap-second-test
- Left leg: bearingstrapprinted.left-leg.bearingstrap
- Left leg: foot-imu-strapprinted.left-leg.foot-imu-strap
- Left leg: heel-bracket_leftprinted.left-leg.heel-bracket-left
- Left leg: heel-bracketleftprinted.left-leg.heel-bracketleft
- Left leg: conjstraint-knee-test-outeprinted.left-leg.conjstraint-knee-test-oute
- Left leg: conjstraint-knee-test-oute_MIRprinted.left-leg.conjstraint-knee-test-oute-mir
- Left leg: 6band (5)printed.left-leg.6band-5
- Left leg: heel-rollerprinted.left-leg.heel-roller
- Left leg: motor-calf-exal-mountprinted.left-leg.motor-calf-exal-mount
- Left leg: bearingstrap-inner-thigh(Mirror) (1)printed.left-leg.bearingstrap-inner-thigh-mirror-1
- Left leg: thigh-bracket(Mirror) (1)printed.left-leg.thigh-bracket-mirror-1
- Left leg: double-bracketprinted.left-leg.double-bracket
- Left leg: HumanoidLeftLeg v22 (1)_ankle-side-bracket123 v2printed.left-leg.humanoidleftleg-v22-1-ankle-side-bracket123-v2
- Left leg: ankle-motor-driver-bracketleftprinted.left-leg.ankle-motor-driver-bracketleft
- Left leg: ankle-motor-driver-bracket_leftprinted.left-leg.ankle-motor-driver-bracket-left
- Left leg: calf-lower-bracket_leftprinted.left-leg.calf-lower-bracket-left
- Left leg: calf-lower-bracketprinted.left-leg.calf-lower-bracket
- Left leg: ankle-side-bracketprinted.left-leg.ankle-side-bracket
- Left leg: bearing-sensor-adapterprinted.left-leg.bearing-sensor-adapter
- Left leg: double-bracket-10deg_MIR_MIR_MIR(Mirror) (1)printed.left-leg.double-bracket-10deg-mir-mir-mir-mirror-1
- Left leg: Toe v1printed.left-leg.toe-v1
- Left leg: multiplex-stackprinted.left-leg.multiplex-stack
- Left leg: calf-skin_flipprinted.left-leg.calf-skin-flip
- Left leg: bearing-sensor-adapter-armprinted.left-leg.bearing-sensor-adapter-arm
- Left leg: knee-lock-2printed.left-leg.knee-lock-2
- Left leg: calf-skinprinted.left-leg.calf-skin
- Left leg: knee-lock-2-bprinted.left-leg.knee-lock-2-b
- Left leg: new-heel-opposingprinted.left-leg.new-heel-opposing
- Left leg: tie-rod-ankle-brackket_left1printed.left-leg.tie-rod-ankle-brackket-left1
- Left leg: tie-rod-ankle-brackket_leftprinted.left-leg.tie-rod-ankle-brackket-left
- Left leg: flank(Mirror) (1)printed.left-leg.flank-mirror-1
- Left leg: flank (1)(Mirror) (1)printed.left-leg.flank-1-mirror-1
- Left leg: calf-coverprinted.left-leg.calf-cover
- Left leg: flank-front (1)(Mirror) (1)printed.left-leg.flank-front-1-mirror-1
- Left leg: flank-front(Mirror) (1)printed.left-leg.flank-front-mirror-1
- Left leg: flank-front-flipped(Mirror) (1)printed.left-leg.flank-front-flipped-mirror-1
- Tools
- Allen keys M4, M5
- Torque
- —
- Time
- 2 h
- After
- 13
- Source
- github.com
- Pelvis22
Pelvis actuators: hip yaw and roll
Mount two RMD-X10 and two CEM-60 in the hip mounts (yaw and roll for each leg) with thread locker, then fix the pelvis ESP32 and CAN module to the frame.
CHECKEach hip yaw and roll axis turns by hand across its range with no rubbing between actuator housings.- Parts in
- MyActuator RMD-X10 (24-48 V, CAN, 50 Nm): 2 torso waist + 2 pelvisactuator.rmd-x10
- MyActuator CEM-60 (48 V, CAN, 20 Nm): 2 pelvis + 4 legs (hip and knee pitch)actuator.cem-60
- ESP32 module, 38-pin (ESP32-DevKitC-V4 / WROOM-32): limb CAN nodeselectronics.esp32
- MCP2515 SPI CAN module (CAN 2.0B, 1 Mbps; must carry an 8 MHz crystal)electronics.can-module
- Socket head cap screw M4 x 55 mm (pelvic 8)fastener.shcs-m4x55
- Socket head cap screw M8 x 40 mm (pelvic 3)fastener.shcs-m8x40
- Tools
- Allen keys, Medium-strength thread locker
- Torque
- —
- Time
- 1 h 30 min
- Source
- github.com
- Torso23
Waist actuators
Mount the waist actuators to the pelvis interface with thread locker: rotation (ID 10), then tilt (ID 11) in its gimbal mount, then lean (ID 12) perpendicular to tilt. The 2026 BOM supplies two RMD-X10 for the torso; the docs describe three waist axes, so confirm your configuration first.
CHECKWaist moves through each axis by hand with no binding (docs QA targets: rotation ±180°, tilt ±30°, lean ±20°).- Parts in
- MyActuator RMD-X10 (24-48 V, CAN, 50 Nm): 2 torso waist + 2 pelvisactuator.rmd-x10
- Socket head cap screw M4 x 45 mm (torso 4, head 6, pelvic 2, legs 2)fastener.shcs-m4x45
- Socket head cap screw M4 x 80 mm (torso 2, legs 10)fastener.shcs-m4x80
- Tools
- Allen keys, Medium-strength thread locker, Torque wrench 0.5-10 Nm
- Torque
- —
- Time
- 1 h 30 min
- Source
- github.com
- 24
Compute bay, power board and cooling
Mount the power distribution board with M3x8 screws and washers at 1.2 Nm. Mount the compute bracket with M4x12 at 3.0 Nm, fit the Jetson on standoffs, and fit the fans with clear airflow paths. Leave service loops on every cable and label each connector.
CHECKThe Jetson bracket does not move under finger pressure, fans spin freely, and every connector carries a label.- Parts in
- NVIDIA Jetson AGX Orin 64GB Developer Kit (275 TOPS)compute.jetson
- Easycargo 30 mm fan, 5 V / 3.3 V DCelectronics.fan-30mm
- Tools
- Torque wrench 0.5-10 Nm, ESD strap, Thermal paste
- Torque
- 3 N·m
- Time
- 2 h
- After
- 16
- Source
- github.com
- Arms25
Mount both arms on the torso
Bolt each shoulder bracket to the torso extrusion and fix one ESP32 + CAN module per arm near the shoulder.
CHECKWith both arms fully raised and lowered by hand, nothing collides with the torso or head mount.- Parts in
- ESP32 module, 38-pin (ESP32-DevKitC-V4 / WROOM-32): limb CAN nodeselectronics.esp32
- MCP2515 SPI CAN module (CAN 2.0B, 1 Mbps; must carry an 8 MHz crystal)electronics.can-module
- Hex lock nut (nylon insert) M4 (arms 36, head 47, pelvic 15)fastener.locknut-m4
- Tools
- Allen keys
- Torque
- —
- Time
- 1 h
- Source
- github.com
- Left leg26
Left leg: ankle tie-rod linkage
Thread the M8 rod ends onto one 210 mm and one 290 mm tie rod, set equal thread engagement at both ends, and connect the calf drive to the ankle brackets.
CHECKBoth ankle axes move through their range by hand without the rod ends reaching the end of their swivel.- Parts in
- Tie rod 8 mm x 210 mm, steel, M8 ends: ankle drivestructure.tie-rod-210
- Tie rod 8 mm x 290 mm, steel, M8 ends: ankle drivestructure.tie-rod-290
- Rod end bearing, female M8x1.25 (FK8)structure.rod-end-m8
- Socket head cap screw M8 x 30 mm (legs 4)fastener.shcs-m8x30
- Socket head cap screw M8 x 35 mm (legs 4)fastener.shcs-m8x35
- Tools
- Allen key M8, Spanner 13 mm
- Torque
- —
- Time
- 1 h 30 min
- After
- 21
- Source
- github.com
- Head27
Mount the head on the torso
Fix the neck base to the neck-chest interface on the torso and route the camera USB and power down to the compute bay.
CHECKThe head reaches full pan/tilt travel without the camera cable tensioning.- Parts in
- —
- Tools
- Allen keys
- Torque
- —
- Time
- 30 min
- Source
- github.com
- Feet28
Mount the feet to the ankles
Attach each foot to its ankle interface through the tie-rod connection, with the sole flat to the ankle roll axis.
CHECKStanding the leg on a flat table, all four load cells of the foot read load.- Parts in
- Feet: foot assembly from foot-v3.stp (TPU 95-98A for the yellow sole parts, PLA for the rest)printed.feet.foot
- Tools
- Allen key set
- Torque
- —
- Time
- 1 h
- Source
- github.com
- Pelvis29
Attach both legs to the pelvis
Bolt each leg's hip pitch stage to its roll stage on the pelvis. Support the lower body on a stand from here on.
CHECKLower body hangs level on the stand, both legs the same length within 2 mm, no visible flex at the hip mounts.- Parts in
- Socket head cap screw M8 x 55 mm (pelvic 2, legs 4)fastener.shcs-m8x55
- Tools
- Allen key M8, A second person or a stand
- Torque
- —
- Time
- 1 h
- Source
- github.com
- Torso30
Join upper and lower body
Safety · human-verified requiredWith the lower body supported on its stand, lower the torso onto the waist interface and bolt it down. Never let the robot bear its own weight on unpowered joints without support.
CHECKThe whole robot hangs from its support with the feet just touching the floor and no joint carrying load against its stop.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- —
- Tools
- Allen keys, Hoist or a second person
- Torque
- —
- Time
- 1 h
- Source
- github.com
- Electrical31
Power harness: battery, BMS, fuses, e-stop
Safety · human-verified requiredBuild the 48 V harness with the BMS on the pack, a fuse on each branch, and the NC e-stop in series with the main feed. Keep every actuator unplugged while building and testing it. Charge only with the 54.6 V charger.
CHECKWith actuators unplugged, every branch reads pack voltage with correct polarity, and pressing the e-stop drops every branch to 0 V.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- 48 V 20 Ah Li-ion pack (960 Wh)power.battery
- 48 V 40 A balancing BMS with NTCpower.bms
- 48 V Li-ion smart charger (54.6 V, 10 A)power.charger
- Inline fuse holder + 40 A blade fusepower.fuse
- Emergency stop button, 22 mm, NC, panel mountpower.estop
- 48 V voltage display module, 3-wirepower.voltmeter
- XT60 female connector, 60 A (pelvis 1, legs 1)cable.xt60-female
- XT60 1-to-2 power splitter (pelvis, legs)cable.xt60-splitter
- Silicone wire 12 AWG, metres (pelvis 1, legs 2)cable.wire-12awg
- Tools
- Soldering iron, XT30/XT60 crimp tool, Digital multimeter
- Torque
- —
- Time
- 3 h
- After
- 30
- Source
- github.com
- 32
Power branches to each subassembly
Safety · human-verified requiredRun XT60 branches to the pelvis and legs and XT30 branches to the torso and arms, one splitter per subassembly as in the BOM. Keep motor stubs short and tie logic and power grounds together.
CHECKContinuity from pack negative to every ESP32 GND; no branch shorted to the frame.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- XT30 female connector, 30 A (torso 2, arms 4, pelvis 1, legs 1)cable.xt30-female
- XT30 1-to-2 power splitter (torso, arms, pelvis, legs)cable.xt30-splitter
- Silicone wire 14 AWG, metres (torso 1, arms 1)cable.wire-14awg
- Tools
- Soldering iron, Digital multimeter
- Torque
- —
- Time
- 2 h
- Source
- github.com
- 33
CAN bus: one ESP32 node per limb
Wire each ESP32 to an SN65HVD230 (GPIO4 to CTX, GPIO5 to CRX, 3V3, GND). Daisy-chain CANH/CANL on twisted pair in a line, no star, stubs under 15 cm. Fit one 120 Ω resistor at each physical end of the bus only.
CHECKWith power off, CANH-to-CANL measures about 60 Ω anywhere on the bus.- Parts in
- ESP32 module, 38-pin (ESP32-DevKitC-V4 / WROOM-32): limb CAN nodeselectronics.esp32
- SN65HVD230 3.3 V CAN transceiver board (one per ESP32 node)electronics.can-transceiver
- 120 Ω 0.25 W termination resistor (one at each physical bus end)electronics.can-termination
- 120 Ω twisted-pair bus cable for CANH/CANL (e.g. one CAT5 pair), 2 m+cable.can-twisted-pair
- Tools
- Soldering iron, Digital multimeter
- Torque
- —
- Time
- 2 h
- After
- 32
- Source
- github.com
- Firmware34
Flash the six limb nodes
Clone dropbear_firmware and flash each board with its environment: `pio run -e left_arm|right_arm|left_leg|right_leg|head|torso --target upload`. The environment injects the CAN node ID (0x10-0x15). Hold BOOT if the upload does not connect.
CHECK`pio device monitor -b 115200` on each node prints its limb name, node_id and `[dropbear] CAN bus online`.- Parts in
- ESP32 module, 38-pin (ESP32-DevKitC-V4 / WROOM-32): limb CAN nodeselectronics.esp32
- Tools
- PlatformIO Core 6.x, USB cable
- Torque
- —
- Time
- 1 h
- After
- 33
- Source
- github.com
- 35
Scan the bus with actuators powered
Safety · human-verified requiredRobot supported, e-stop in reach. Power one limb branch at a time and read status (0x9A) from every actuator on it: temperature, voltage and error flags. Set a watchdog (0xB3, 200-500 ms) and a conservative acceleration (0x43) on each.
CHECKEvery expected ID answers with pack voltage and no error flags; unplugging the brain stops motion within the watchdog time.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- MyActuator RMD-X10 (24-48 V, CAN, 50 Nm): 2 torso waist + 2 pelvisactuator.rmd-x10
- MyActuator RMD-X8 (24-48 V, CAN, 24 Nm): legsactuator.rmd-x8
- MyActuator RMD-X6 (24 V, CAN, 8 Nm): armsactuator.rmd-x6
- MyActuator CEM-60 (48 V, CAN, 20 Nm): 2 pelvis + 4 legs (hip and knee pitch)actuator.cem-60
- Tools
- myactuator-can, MyActuator USB-CAN tool
- Torque
- —
- Time
- 1 h
- After
- 34
- Source
- github.com
- Bring-up36
Observation-only bring-up
Safety · human-verified requiredFlash the observation-safe leg image (motion commands disabled; it reports five AS5600 and six motor CAN angles) or use the dropbear_control dashboard in receive-only mode. Move each joint by hand and watch the reported angle.
CHECKEvery joint's reported angle changes in the same direction as the URDF joint axis when moved by hand.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- —
- Tools
- dropbear_control dashboard
- Torque
- —
- Time
- 1 h
- After
- 35
- Source
- github.com
- 37
Zero positions and joint limits
Safety · human-verified requiredPut each joint at its mechanical reference and store zero with 0x64. Record direction and soft limits for every joint and compare them with the URDF/MJCF joint ranges. The upstream calibration docs are marked 'coming soon', so log what you measure.
CHECKCommanding each joint to zero puts the robot in the URDF zero pose within a few degrees, and soft limits stop motion before any hard stop.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- —
- Tools
- Angle gauge or printed jig
- Torque
- —
- Time
- 3 h
- After
- 36
- Source
- github.com
- 38
First powered motion, one joint at a time
Safety · human-verified requiredRobot hanging from its support. Command small absolute moves (0xA4) with a low speed limit on one joint at a time, then small coordinated poses per limb. Keep the e-stop in hand.
CHECKEach joint reaches a ±10° target and returns to zero with actuator temperature below 60 °C.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- —
- Tools
- myactuator-can
- Torque
- —
- Time
- 2 h
- After
- 37
- Source
- github.com
- 39
Rehearse the published policy in simulation
Install dropbear_walk into Isaac Lab and play the v0.1.0 checkpoint (model_8745.pt) in the live viewer. It takes 58 observations and emits 14 joint-position actions at 50 Hz; do not send those raw values to hardware. These are simulation releases; the repo states physical walking still needs separate validation.
CHECKThe v0.1.0 policy walks the simulated robot at the 0.20 m/s command without falling for a 20 s episode.- Parts in
- —
- Tools
- Isaac Sim 6.0.0 + Isaac Lab @a4a7602, NVIDIA GPU
- Torque
- —
- Time
- 2 h
- After
- 37
- Source
- github.com
- 40
First supported stand
Safety · human-verified requiredNo stand or walking procedure for hardware is published upstream. Keep the robot on a slack fall-arrest line, lower it until the feet carry weight under a position-hold pose, and cut power with the e-stop at any unexpected motion. Do not run a learned policy on hardware until its observation, action scaling and control rate are reproduced.
CHECKThe robot holds the stand pose for 30 s with the line slack, both feet loaded per the foot sensors, and no actuator above 60 °C.This step can hurt a person or ruin parts. Its instructions need sign-off by a human who has done it before relying on them. Stop and ask if anything differs from what you see.
- Parts in
- —
- Tools
- Overhead hoist or gantry with a fall-arrest line
- Torque
- —
- Time
- 1 h
- Source
- github.com
Progress is stored in this browser only (localStorage). Nothing is sent anywhere.
Bring-up
Flash · calibrate · first policy- A
Flash firmware
Targetsleft_arm, right_arm, left_leg, right_leg, head, torso, neck (Dropbear-Neck-Assembly), feet (dropbear-feet pressure.ino)
Repogithub.com/Hyperspawn/dropbear_firmware
dropbear_firmware: PlatformIO / Arduino on ESP32-DevKitC-V4, SN65HVD230 transceivers, one shared 1 Mbit/s CAN bus, node IDs 0x10-0x15, 500 Hz joint state, 1 Hz heartbeat; CI builds all six limb environments. Per-limb joints: arms 7, legs 6, head 3, torso 2 (31 total). The main Dropbear repo keeps the original low-level controllers: the Behemoth universal image (left leg, right leg, center IMU or head/neck role from persistent config), a hybrid PWM/CAN leg controller, an observation-only image and a legacy leg controller; its partitions.csv gives the app 2.5 MiB. robit-man/dropbear_control provides a browser digital twin and a guarded firmware uploader that checks the partition table.
- B
Calibrate
CalibrationSet actuator IDs (0x79) and zero (0x64) with myactuator-can, then verify joint directions against the URDF using the observation-safe image before any motion.Log the output. It goes in your build report.
- C
First policy
- walk, flat ground (v0.1.0, validated in sim)Isaac Lab + RSL-RL PPO source
- walk over low obstacles (v0.2.0, experimental)Isaac Lab + RSL-RL PPO source
Try the policy in the browser sim before it touches hardware. Keep a hand near the power switch the first time a policy runs on the real robot.
Report your build
Moves Dropbear toward L4 · BuiltA build report is the only thing that proves a package works. It raises the level, puts a point on the map, and tells the Foreman which steps to rewrite.
Level gate
Holds L2 · evidence, not confidence- L0Indexed
Known to exist. Atlas page only.
- 16 sources on record(met)
- L1Compiled
Package validates against the spec; every fact has a source.
- Build package compiled(met)
- 32 sources across robot and package(met)
- L2Sim-verified
Loads in browser and GPU sim, mass within tolerance of the BOM, holds a stand. Unlocks .training.
- URDF/MJCF is public(met)
- Sim load, mass tolerance and stand are checked on .training(checked elsewhere)
- L3Sourced
Every BOM line resolves to a live offer in at least two regions. Unlocks the one-click cart.
- 76/94 BOM lines have offers in 2+ regions(not met)
- L4Built
At least one community build report with photos and bring-up logs. Unlocks Build it as the main action.
- 0 reviewed build reports(not met)
- Review feed unreachable at last refresh; count is registry-only(checked elsewhere)
- L5Certified
The robot's maintainer signs the package. Unlocks certified teams and kit sales.
- Maintainer signature not recorded(not met)
Levels are cumulative and set by the registry from reviewed evidence. This panel shows what can be measured from the package today.